Linear solver. More...
#include <linsol.hpp>
Solves the square linear system A*X = B or A'*X = B for X with a sparse direct solver plugin. A Linsol is created for a fixed sparsity pattern of A; the numerical values are given at every call. A matrix with another sparsity pattern is projected onto the fixed one (entries outside it are dropped). The solve is split in a symbolic factorization (sfact, pivot selection from the pattern), a numeric factorization (nfact) and the triangular solves (solve); solve(A, B) performs all three. A numerically singular matrix makes nfact (or solve) raise an error for most plugins; for a symbolic (MX) A, solve returns an expression node that is differentiable with respect to A and B.
Available plugins include "qr" and "ldl" (sparse direct QR and LDL, codegen support), "symbolicqr" (QR as a symbolic expression), "csparse", "csparsecholesky", "lapacklu", "lapackqr", "ma27", "mumps". neig and rank are only implemented by "ldl", det by "qr" and "csparse". The constructor raises an error for a non-square pattern only when the plugin checks it; otherwise the solve fails.
>>> A = DM([[3, 1], [1, 2]]); b = DM([4, 3])
>>> L = Linsol("L", "qr", A.sparsity())
>>> L.plugin_name(), L.sparsity()
('qr', Sparsity(2x2))
>>> L.solve(A, b), L.solve(DM([[1, 2], [0, 1]]), DM([1, 1]), True)
(DM([1, 1]), DM([1, -1]))
>>> L.solve(A, DM([[4, 1], [3, 0]]))
DM(
[[1, 0.4],
 [1, -0.2]])
>>> L.det(A)
5.0
>>> try:
...     L.solve(DM([[1, 1], [1, 1]]), b)
... except RuntimeError as e:
...     print("'nfact' failed" in str(e))
True
>>> Am = MX.sym("A", A.sparsity()); bm = MX.sym("b", 2)
>>> f = Function("f", [Am, bm], [L.solve(Am, bm), L.det(Am)])
>>> f(A, b)
(DM([1, 1]), DM(5))
>> A = DM([3 1; 1 2]); b = DM([4; 3]);
>> L = Linsol('L', 'qr', A.sparsity());
>> L.plugin_name(), L.sparsity()
qr
2x2
>> L.solve(A, b), L.solve(DM([1 2; 0 1]), DM([1; 1]), true)
[1, 1]
[1, -1]
>> L.solve(A, DM([4 1; 3 0]))
[[1, 0.4],
 [1, -0.2]]
>> L.det(A)
5
>> try, L.solve(DM([1 1; 1 1]), b); catch e, msg = e.message; end
>> contains(msg, '''nfact'' failed')
1
>> Am = MX.sym('A', A.sparsity()); bm = MX.sym('b', 2);
>> f = Function('f', {Am, bm}, {L.solve(Am, bm), L.det(Am)});
>> [xs, d] = f(A, b); disp(xs), disp(d)
[1, 1]
5
julia> A = ca.DM([3 1; 1 2]); b = ca.DM([4, 3]);
julia> L = ca.Linsol("L", "qr", ca.sparsity(A));
julia> ca.plugin_name(L), ca.sparsity(L)
("qr", 2x2)
julia> ca.solve(L, A, b)
DM([1, 1])
julia> ca.solve(L, ca.DM([1 2; 0 1]), ca.DM([1, 1]), true)
DM([1, -1])
julia> ca.solve(L, A, ca.DM([4 1; 3 0]))
DM(
[[1, 0.4],
 [1, -0.2]])
julia> L.det(A)
5.0
julia> try
           ca.solve(L, ca.DM([1 1; 1 1]), b, false)
       catch e
           println(occursin("'nfact' failed", sprint(showerror, e)))
       end
true
julia> Am = ca.MX.sym("A", ca.sparsity(A)); bm = ca.MX.sym("b", 2);
julia> f = ca.Function("f", [Am, bm], [ca.solve(L, Am, bm), L.det(Am)]);
julia> f(A, b)
([1, 1], 5)
- csparse
- ma27
- lapacklu
- lapackqr
- mumps
- ldl
- qr
- tridiag
Note: some of the plugins in this list might not be available on your system. Also, there might be extra plugins available to you that are not listed here. You can obtain their documentation with Linsol.doc("myextraplugin")
Linsol with CSparseCholesky Interface
Extra doc: https://github.com/casadi/casadi/wiki/L_21u
Linsol with CSparse Interface
Extra doc: https://github.com/casadi/casadi/wiki/L_21t
Interface to the sparse direct linear solver MA27 Works for symmetric indefinite systems Partly adopted from qpOASES 3.2
Extra doc: https://github.com/casadi/casadi/wiki/L_229
This class solves the linear system A.x=b by making an LU factorization of A:
A = L.U, with L lower and U upper triangular
Extra doc: https://github.com/casadi/casadi/wiki/L_22h
| Id | Type | Description |
|---|---|---|
| allow_equilibration_failure | OT_BOOL | Non-fatal error when equilibration fails |
| equilibration | OT_BOOL | Equilibrate the matrix |
This class solves the linear system A.x=b by making an QR factorization of A:
A = Q.R, with Q orthogonal and R upper triangular
Extra doc: https://github.com/casadi/casadi/wiki/L_22g
| Id | Type | Description |
|---|---|---|
| max_nrhs | OT_INT | Maximum number of right-hand-sides that get processed in a single pass [default:10]. |
Interface to the sparse direct linear solver MUMPS Works for symmetric indefinite systems
Extra doc: https://github.com/casadi/casadi/wiki/L_22t
| Id | Type | Description |
|---|---|---|
| posdef | OT_BOOL | Positive definite |
| symmetric | OT_BOOL | Symmetric matrix |
Linear solver using sparse direct LDL factorization
Extra doc: https://github.com/casadi/casadi/wiki/L_233
| Id | Type | Description |
|---|---|---|
| incomplete | OT_BOOL | Incomplete factorization, without any fill-in |
| preordering | OT_BOOL | Approximate minimal degree (AMD) preordering |
Linear solver using sparse direct QR factorization
Extra doc: https://github.com/casadi/casadi/wiki/L_22z
| Id | Type | Description |
|---|---|---|
| cache | OT_DOUBLE | Amount of factorisations to remember (thread-local) [0] |
| eps | OT_DOUBLE | Minimum R entry before singularity is declared [1e-12] |
Linear solver for tridiagonal matrices
Extra doc: https://github.com/casadi/casadi/wiki/L_22v
Linear solver for sparse least-squares problems Inspired from https://github.com/scipy/scipy/blob/v0.14.0/scipy/sparse/linalg/isolve/lsqr.py#L96
Extra doc: https://github.com/casadi/casadi/wiki/L_230
Linsol based on QR factorization with sparsity pattern based reordering without partial pivoting
Extra doc: https://github.com/casadi/casadi/wiki/L_231
| Id | Type | Description |
|---|---|---|
| fopts | OT_DICT | Options to be passed to generated function objects |
Extra doc: https://github.com/casadi/casadi/wiki/L_1kh
Definition at line 142 of file linsol.hpp.
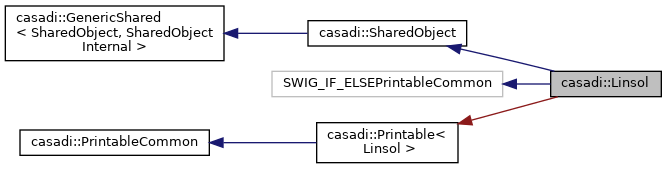
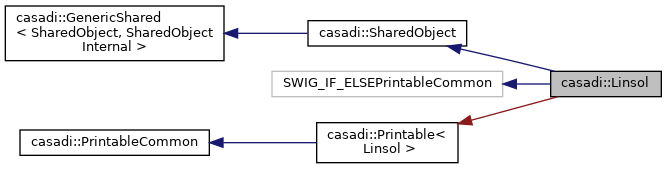
Public Types | |
| using | internal_base_type = SharedObjectInternal |
| using | base_type = SharedObject |
Public Member Functions | |
| Linsol () | |
| Default constructor (a null object) More... | |
| Linsol (const std::string &name, const std::string &solver, const Sparsity &sp, const Dict &opts=Dict()) | |
| Create a linear solver. More... | |
| LinsolInternal * | operator-> () |
| Access functions of the node. More... | |
| const LinsolInternal * | operator-> () const |
| std::string | plugin_name () const |
| Query plugin name. More... | |
| const Sparsity & | sparsity () const |
| Get the sparsity pattern of A fixed at construction. More... | |
| void | sfact (const DM &A) const |
| Symbolic factorization of the linear system, e.g. selecting pivots. More... | |
| void | nfact (const DM &A) const |
| Numeric factorization of the linear system. More... | |
| casadi_int | neig (const DM &A) const |
| Number of negative eigenvalues. More... | |
| casadi_int | rank (const DM &A) const |
| Matrix rank. More... | |
| double | det (const DM &A) const |
| Matrix determinant. More... | |
| MX | det (const MX &A) const |
| Matrix determinant as an MX graph node. More... | |
| Dict | stats (int mem=1) const |
| Get all statistics obtained at the end of the last evaluate call. More... | |
| casadi_int | checkout () const |
| Checkout a memory object. More... | |
| void | release (int mem) const |
| Release a memory object. More... | |
| void | serialize (SerializingStream &s) const |
| Serialize an object. More... | |
| std::string | class_name () const |
| Get class name. More... | |
| void | disp (std::ostream &stream, bool more=false) const |
| Print a description of the object. More... | |
| std::string | get_str (bool more=false) const |
| Get string representation. More... | |
| void | print_ptr (std::ostream &stream=casadi::uout()) const |
| void | own (SharedObjectInternal *node) |
| void | assign (SharedObjectInternal *node) |
| Assign the node to a node class pointer without reference counting. More... | |
| SharedObjectInternal * | get () const |
| Get a const pointer to the node. More... | |
| casadi_int | getCount () const |
| Get the reference count. More... | |
| void | swap (GenericShared &other) |
| Swap content with another instance. More... | |
| std::string | debug_repr () const |
| bool | is_null () const |
| Is a null pointer? More... | |
| casadi_int | __hash__ () const |
| Returns a number that is unique for a given Node. More... | |
| GenericWeakRef< SharedObject, SharedObjectInternal > * | weak () |
| Get a weak reference to the object. More... | |
| DM | solve (const DM &A, const DM &B, bool tr=false) const |
Solve the linear system A*X = B (or A'*X = B with tr true) More... | |
| MX | solve (const MX &A, const MX &B, bool tr=false) const |
Solve the linear system A*X = B (or A'*X = B with tr true) More... | |
| int | sfact (const double *A, int mem=0) const |
| int | nfact (const double *A, int mem=0) const |
| int | solve (const double *A, double *x, casadi_int nrhs=1, bool tr=false, int mem=0) const |
| double | det (const double *A, int mem=0) const |
| casadi_int | neig (const double *A, int mem=0) const |
| casadi_int | rank (const double *A, int mem=0) const |
Static Public Member Functions | |
| static std::string | type_name () |
| Get type name. More... | |
| static bool | test_cast (const SharedObjectInternal *ptr) |
| Check if a particular cast is allowed. More... | |
| static Linsol | create (LinsolInternal *node) |
| Create from node. More... | |
| static bool | has_plugin (const std::string &name) |
| Check if a plugin is available. More... | |
| static void | load_plugin (const std::string &name) |
| Explicitly load a plugin dynamically. More... | |
| static std::string | doc (const std::string &name) |
| Get solver specific documentation. More... | |
| static Linsol | deserialize (DeserializingStream &s) |
| Deserialize with type disambiguation. More... | |
Protected Member Functions | |
| void | count_up () |
| void | count_down () |
|
inherited |
Definition at line 103 of file shared_object.hpp.
|
inherited |
Definition at line 102 of file shared_object.hpp.
| casadi::Linsol::Linsol | ( | ) |
Definition at line 32 of file linsol.cpp.
|
explicit |
| name | Name of the solver object |
| solver | Plugin name, e.g. "qr", "ldl", "csparse"; see has_linsol |
| sp | Sparsity pattern of A (square); the numerical values are given at every call |
| opts | Options; an unknown option raises an error |
>>> L = Linsol("L", "ldl", Sparsity.dense(2, 2))
>>> L
Linsol(Linear solver LinsolLdl)
>>> try:
...     Linsol("L", "qr", Sparsity.dense(2, 2), {"no_such_option": 1})
... except RuntimeError as e:
...     print("Unknown option" in str(e))
True
>> L = Linsol('L', 'ldl', Sparsity.dense(2, 2)); disp(L)
Linear solver LinsolLdl
>> opts = struct('no_such_option', 1);
>> try, Linsol('L', 'qr', Sparsity.dense(2, 2), opts); catch e, msg = e.message; end
>> contains(msg, 'Unknown option')
1
julia> L = ca.Linsol("L", "ldl", ca.Sparsity.dense(2, 2));
julia> ca.str(L)
"Linear solver LinsolLdl"
julia> try
           ca.Linsol("L", "qr", ca.Sparsity.dense(2, 2), Dict("no_such_option" => 1))
       catch e
           println(occursin("Unknown option", sprint(showerror, e)))
       end
true
Extra doc: https://github.com/casadi/casadi/wiki/L_2pe
Definition at line 35 of file linsol.cpp.
References casadi::PluginInterface< LinsolInternal >::getPlugin(), and casadi::GenericShared< SharedObject, SharedObjectInternal >::own().
|
inherited |
If the Object does not point to any node, "0" is returned.
Extra doc: https://github.com/casadi/casadi/wiki/L_av
Definition at line 123 of file generic_shared_impl.hpp.
|
inherited |
improper use will cause memory leaks!
Extra doc: https://github.com/casadi/casadi/wiki/L_at
Definition at line 96 of file generic_shared_impl.hpp.
| casadi_int casadi::Linsol::checkout | ( | ) | const |
Definition at line 223 of file linsol.cpp.
Referenced by casadi::SundialsInterface::init_mem(), and casadi::Ipqp::solve().
|
inherited |
Extra doc: https://github.com/casadi/casadi/wiki/L_au
Definition at line 31 of file shared_object.cpp.
Referenced by casadi::FmuFunction::check_mem_count(), casadi::MXFunction::export_code_body(), and casadi::BlazingSplineFunction::merge().
|
protectedinherited |
Definition at line 133 of file generic_shared_impl.hpp.
|
protectedinherited |
Definition at line 132 of file generic_shared_impl.hpp.
|
static |
Extra doc: https://github.com/casadi/casadi/wiki/L_1kj
Definition at line 262 of file linsol.cpp.
References casadi::GenericShared< Shared, Internal >::own().
|
inherited |
Definition at line 112 of file generic_shared_impl.hpp.
|
static |
Extra doc: https://github.com/casadi/casadi/wiki/L_1kn
Definition at line 255 of file linsol.cpp.
References casadi::LinsolInternal::deserialize(), casadi::ProtoFunction::finalize(), and casadi::GenericShared< Shared, Internal >::own().
| double casadi::Linsol::det | ( | const DM & | A | ) | const |
Not available for all solvers ("qr" and "csparse"); factorizes A first.
>>> A = DM([[3, 1], [1, 2]])
>>> Linsol("L", "qr", A.sparsity()).det(A)
5.0
>>> try:
...     Linsol("L", "ldl", A.sparsity()).det(A)
... except RuntimeError as e:
...     print("'det' not defined" in str(e))
True
>> A = DM([3 1; 1 2]); L = Linsol('L', 'qr', A.sparsity()); disp(L.det(A))
5
>> L = Linsol('L', 'ldl', A.sparsity());
>> try, L.det(A); catch e, disp(contains(e.message, '''det'' not defined')); end
1
julia> A = ca.DM([3 1; 1 2]);
julia> ca.Linsol("L", "qr", ca.sparsity(A)).det(A)
5.0
julia> try
           ca.Linsol("L", "ldl", ca.sparsity(A)).det(A)
       catch e
           println(occursin("'det' not defined", sprint(showerror, e)))
       end
true
Extra doc: https://github.com/casadi/casadi/wiki/L_2hw
Definition at line 198 of file linsol.cpp.
References nfact(), casadi::Matrix< Scalar >::ptr(), sfact(), sparsity(), and casadi::Matrix< Scalar >::sparsity().
Referenced by casadi::MX::det(), casadi::Determinant::eval(), and casadi::Determinant::eval_mx().
| double casadi::Linsol::det | ( | const double * | A, |
| int | mem = 0 |
||
| ) | const |
Low-level API
Definition at line 174 of file linsol.cpp.
Definition at line 206 of file linsol.cpp.
References casadi::MXNode::get_det().
|
inherited |
Definition at line 35 of file shared_object.cpp.
References casadi::GenericShared< SharedObject, SharedObjectInternal >::is_null().
Referenced by casadi::WeakRefInternal::disp(), casadi::Nlpsol::disp_more(), and casadi::CsparseInterface::nfact().
|
static |
Same as doc_linsol.
>>> "LDL" in Linsol.doc("ldl")
True
>> contains(Linsol.doc('ldl'), 'LDL')
1
julia> occursin("LDL", ca.Linsol.doc("ldl"))
true
Extra doc: https://github.com/casadi/casadi/wiki/L_2ph
Definition at line 61 of file linsol.cpp.
References casadi::PluginInterface< LinsolInternal >::getPlugin().
Referenced by casadi::doc_linsol().
|
inherited |
Definition at line 99 of file generic_shared_impl.hpp.
|
inlineinherited |
Definition at line 91 of file shared_object.hpp.
|
inherited |
Definition at line 102 of file generic_shared_impl.hpp.
|
static |
Same as has_linsol.
>>> Linsol.has_plugin("qr"), Linsol.has_plugin("no_such_plugin")
(True, False)
>> Linsol.has_plugin('qr'), Linsol.has_plugin('no_such_plugin')
1
0
julia> ca.Linsol.has_plugin("qr"), ca.Linsol.has_plugin("no_such_plugin")
(true, false)
Extra doc: https://github.com/casadi/casadi/wiki/L_2pf
Definition at line 53 of file linsol.cpp.
References casadi::PluginInterface< LinsolInternal >::has_plugin().
Referenced by casadi::has_linsol().
|
inherited |
Definition at line 116 of file generic_shared_impl.hpp.
|
static |
Same as load_linsol; raises an error when the plugin cannot be found.
>>> try:
...     Linsol.load_plugin("no_such_plugin")
... except RuntimeError as e:
...     print("no_such_plugin" in str(e))
True
>> try, Linsol.load_plugin('no_such_plugin'); catch e, msg = e.message; end
>> contains(msg, 'no_such_plugin')
1
julia> try
           ca.Linsol.load_plugin("no_such_plugin")
       catch e
           println(occursin("no_such_plugin", sprint(showerror, e)))
       end
true
Extra doc: https://github.com/casadi/casadi/wiki/L_2pg
Definition at line 57 of file linsol.cpp.
References casadi::PluginInterface< LinsolInternal >::load_plugin().
Referenced by casadi::load_linsol().
| casadi_int casadi::Linsol::neig | ( | const DM & | A | ) | const |
Not available for all solvers (only "ldl"); uses the factorization of the most recent nfact call, which must have been made with the same matrix.
>>> A = DM([[-2, 0], [0, 1]])
>>> L = Linsol("L", "ldl", A.sparsity())
>>> L.nfact(A)
>>> L.neig(A)
1
>>> try:
...     Linsol("L", "qr", A.sparsity()).neig(A)
... except RuntimeError as e:
...     print("'neig' not defined" in str(e))
True
>> A = DM([-2 0; 0 1]); L = Linsol('L', 'ldl', A.sparsity());
>> L.nfact(A); disp(L.neig(A))
1
>> L = Linsol('L', 'qr', A.sparsity());
>> try, L.neig(A); catch e, disp(contains(e.message, '''neig'' not defined')); end
1
julia> A = ca.DM([-2 0; 0 1]);
julia> L = ca.Linsol("L", "ldl", ca.sparsity(A));
julia> ca.nfact(L, A)
julia> ca.neig(L, A)
1
julia> try
           ca.neig(ca.Linsol("L", "qr", ca.sparsity(A)), A)
       catch e
           println(occursin("'neig' not defined", sprint(showerror, e)))
       end
true
Extra doc: https://github.com/casadi/casadi/wiki/L_1kk
Definition at line 180 of file linsol.cpp.
References casadi::Matrix< Scalar >::ptr(), sparsity(), and casadi::Matrix< Scalar >::sparsity().
Referenced by casadi::QpoasesInterface::qpoases_nfact().
| casadi_int casadi::Linsol::neig | ( | const double * | A, |
| int | mem = 0 |
||
| ) | const |
Low-level API
Definition at line 187 of file linsol.cpp.
| void casadi::Linsol::nfact | ( | const DM & | A | ) | const |
Factorizes the values of A (after sfact if not done yet), so that neig, rank and the low-level solve can use the factorization. Raises an error when the factorization fails with option "regularity_check" set; otherwise a failure is only reported by solve.
>>> A = DM([[3, 1], [1, 2]])
>>> L = Linsol("L", "ldl", A.sparsity())
>>> L.nfact(A)
>>> L.neig(A), L.rank(A)
(0, 2)
>>> L.nfact(DM([[-1, 0], [0, 1]]))
>>> L.neig(DM([[-1, 0], [0, 1]]))
1
>> A = DM([3 1; 1 2]); L = Linsol('L', 'ldl', A.sparsity());
>> L.nfact(A); fprintf('%d %d\n', L.neig(A), L.rank(A))
0 2
>> B = DM([-1 0; 0 1]); L.nfact(B); disp(L.neig(B))
1
julia> A = ca.DM([3 1; 1 2]);
julia> L = ca.Linsol("L", "ldl", ca.sparsity(A));
julia> ca.nfact(L, A)
julia> ca.neig(L, A), ca.rank(L, A)
(0, 2)
julia> ca.nfact(L, ca.DM([-1 0; 0 1]))
julia> ca.neig(L, ca.DM([-1 0; 0 1]))
1
Extra doc: https://github.com/casadi/casadi/wiki/L_2pj
Definition at line 133 of file linsol.cpp.
References casadi::Matrix< Scalar >::ptr(), sparsity(), and casadi::Matrix< Scalar >::sparsity().
Referenced by det(), casadi::Determinant::eval(), casadi::SlicotDple::eval(), casadi::KinsolInterface::psetup(), casadi::QpoasesInterface::qpoases_nfact(), solve(), casadi::Ipqp::solve(), and casadi::Newton::solve().
| int casadi::Linsol::nfact | ( | const double * | A, |
| int | mem = 0 |
||
| ) | const |
Low-level API
Definition at line 141 of file linsol.cpp.
References casadi::Sparsity::export_code(), casadi::LinsolMemory::is_nfact, casadi::Filesystem::ofstream_ptr(), sfact(), and sparsity().
| LinsolInternal * casadi::Linsol::operator-> | ( | ) |
Definition at line 41 of file linsol.cpp.
References casadi::GenericShared< SharedObject, SharedObjectInternal >::operator->().
| const LinsolInternal * casadi::Linsol::operator-> | ( | ) | const |
Definition at line 45 of file linsol.cpp.
References casadi::GenericShared< SharedObject, SharedObjectInternal >::operator->().
|
inherited |
Assign the node to a node class pointer (or null)
Definition at line 89 of file generic_shared_impl.hpp.
| std::string casadi::Linsol::plugin_name | ( | ) | const |
Definition at line 65 of file linsol.cpp.
|
inherited |
Print the pointer to the internal class
Definition at line 43 of file shared_object.cpp.
References casadi::GenericShared< SharedObject, SharedObjectInternal >::get().
| casadi_int casadi::Linsol::rank | ( | const DM & | A | ) | const |
Not available for all solvers (only "ldl"); uses the factorization of the most recent nfact call, which must have been made with the same matrix.
A rank-deficient matrix also triggers a warning in nfact.
>>> A = DM([[2, 1], [1, 3]])
>>> L = Linsol("L", "ldl", A.sparsity())
>>> L.nfact(A)
>>> L.rank(A)
2
>> A = DM([2 1; 1 3]); L = Linsol('L', 'ldl', A.sparsity());
>> L.nfact(A); disp(L.rank(A))
2
julia> A = ca.DM([2 1; 1 3]);
julia> L = ca.Linsol("L", "ldl", ca.sparsity(A));
julia> ca.nfact(L, A)
julia> ca.rank(L, A)
2
Extra doc: https://github.com/casadi/casadi/wiki/L_1kl
Definition at line 191 of file linsol.cpp.
References casadi::Matrix< Scalar >::ptr(), sparsity(), and casadi::Matrix< Scalar >::sparsity().
Referenced by casadi::QpoasesInterface::qpoases_nfact().
| casadi_int casadi::Linsol::rank | ( | const double * | A, |
| int | mem = 0 |
||
| ) | const |
Low-level API
Definition at line 210 of file linsol.cpp.
| void casadi::Linsol::release | ( | int | mem | ) | const |
Definition at line 227 of file linsol.cpp.
Referenced by casadi::Ipqp::solve().
| void casadi::Linsol::serialize | ( | SerializingStream & | s | ) | const |
Extra doc: https://github.com/casadi/casadi/wiki/L_1km
Definition at line 250 of file linsol.cpp.
| void casadi::Linsol::sfact | ( | const DM & | A | ) | const |
Only uses the sparsity pattern of A. Called automatically by nfact and solve when needed; raises an error when the plugin fails.
Extra doc: https://github.com/casadi/casadi/wiki/L_2pi
Definition at line 108 of file linsol.cpp.
References casadi::Matrix< Scalar >::ptr(), sparsity(), and casadi::Matrix< Scalar >::sparsity().
Referenced by det(), casadi::Determinant::eval(), casadi::SlicotDple::eval(), nfact(), casadi::QpoasesInterface::qpoases_sfact(), and solve().
| int casadi::Linsol::sfact | ( | const double * | A, |
| int | mem = 0 |
||
| ) | const |
For DM arguments, factorizes A and solves for all columns of B at once; the result is dense. For MX arguments, returns an expression node that is differentiable. The row count of A and B must match.
| A | Square matrix with the sparsity pattern given at construction (projected onto it otherwise) |
| B | Right-hand side, one column per system to solve |
| tr | Solve with the transpose of A instead |
B
>>> L = Linsol("L", "qr", Sparsity.dense(2, 2))
>>> L.solve(DM([[3, 1], [1, 2]]), DM([4, 3]))
DM([1, 1])
>>> try:
...     L.solve(DM([[3, 1], [1, 2]]), DM([1, 2, 3]))
... except RuntimeError as e:
...     print("matching row count" in str(e))
True
>> L = Linsol('L', 'qr', Sparsity.dense(2, 2));
>> L.solve(DM([3 1; 1 2]), DM([4; 3]))
[1, 1]
>> try, L.solve(DM([3 1; 1 2]), DM([1; 2; 3])); catch e, msg = e.message; end
>> contains(msg, 'matching row count')
1
julia> L = ca.Linsol("L", "qr", ca.Sparsity.dense(2, 2));
julia> ca.solve(L, ca.DM([3 1; 1 2]), ca.DM([4, 3]))
DM([1, 1])
julia> try
           ca.solve(L, ca.DM([3 1; 1 2]), ca.DM([1, 2, 3]))
       catch e
           println(occursin("matching row count", sprint(showerror, e)))
       end
true
Extra doc: https://github.com/casadi/casadi/wiki/L_2pk
Definition at line 73 of file linsol.cpp.
References casadi::GenericMatrix< MatType >::dim(), nfact(), casadi::Matrix< Scalar >::ptr(), sfact(), casadi::GenericMatrix< MatType >::size1(), casadi::GenericMatrix< MatType >::size2(), casadi::ProtoFunctionMemory::t_total, and casadi::FStats::tic().
Referenced by casadi::SlicotDple::eval(), casadi::KinsolInterface::psolve(), casadi::QpoasesInterface::qpoases_solve(), casadi::Ipqp::solve(), casadi::LinsolCall< Tr >::solve(), casadi::MX::solve(), casadi::Newton::solve(), and casadi::IdasInterface::solve_transposed().
| int casadi::Linsol::solve | ( | const double * | A, |
| double * | x, | ||
| casadi_int | nrhs = 1, |
||
| bool | tr = false, |
||
| int | mem = 0 |
||
| ) | const |
For DM arguments, factorizes A and solves for all columns of B at once; the result is dense. For MX arguments, returns an expression node that is differentiable. The row count of A and B must match.
| A | Square matrix with the sparsity pattern given at construction (projected onto it otherwise) |
| B | Right-hand side, one column per system to solve |
| tr | Solve with the transpose of A instead |
B
>>> L = Linsol("L", "qr", Sparsity.dense(2, 2))
>>> L.solve(DM([[3, 1], [1, 2]]), DM([4, 3]))
DM([1, 1])
>>> try:
...     L.solve(DM([[3, 1], [1, 2]]), DM([1, 2, 3]))
... except RuntimeError as e:
...     print("matching row count" in str(e))
True
>> L = Linsol('L', 'qr', Sparsity.dense(2, 2));
>> L.solve(DM([3 1; 1 2]), DM([4; 3]))
[1, 1]
>> try, L.solve(DM([3 1; 1 2]), DM([1; 2; 3])); catch e, msg = e.message; end
>> contains(msg, 'matching row count')
1
julia> L = ca.Linsol("L", "qr", ca.Sparsity.dense(2, 2));
julia> ca.solve(L, ca.DM([3 1; 1 2]), ca.DM([4, 3]))
DM([1, 1])
julia> try
           ca.solve(L, ca.DM([3 1; 1 2]), ca.DM([1, 2, 3]))
       catch e
           println(occursin("matching row count", sprint(showerror, e)))
       end
true
Extra doc: https://github.com/casadi/casadi/wiki/L_2pk
Definition at line 104 of file linsol.cpp.
References casadi::MXNode::get_solve().
| const Sparsity & casadi::Linsol::sparsity | ( | ) | const |
Definition at line 69 of file linsol.cpp.
Referenced by det(), casadi::SundialsInterface::init(), neig(), nfact(), rank(), casadi::SundialsInterface::set_work(), and sfact().
| Dict casadi::Linsol::stats | ( | int | mem = 1 | ) | const |
Plugin-specific; empty for most plugins. Raises an error before the first solve. With the option "record_time" set, it holds call counts and timings (n_call_*, t_proc_*, t_wall_*) of sfact, nfact and solve.
>>> L = Linsol("L", "qr", Sparsity.dense(1, 1))
>>> try:
...     L.stats()
... except RuntimeError as e:
...     print("did not solve a problem yet" in str(e))
True
>>> L.solve(DM(2), DM(4)), L.stats()
(DM(2), {})
>>> L = Linsol("L", "qr", Sparsity.dense(1, 1), {"record_time": True})
>>> L.solve(DM(2), DM(4)); L.stats()["n_call_solve"]
DM(2)
1
>> L = Linsol('L', 'qr', Sparsity.dense(1, 1));
>> try, L.stats(); catch e, disp(contains(e.message, 'did not solve a problem yet')); end
1
>> L.solve(DM(2), DM(4)), isempty(fieldnames(L.stats()))
2
1
julia> L = ca.Linsol("L", "qr", ca.Sparsity.dense(1, 1));
julia> try
           ca.stats(L)
       catch e
           println(occursin("did not solve a problem yet", sprint(showerror, e)))
       end
true
julia> ca.solve(L, ca.DM(2), ca.DM(4)), ca.stats(L)
(2, Dict{String, Any}())
julia> L = ca.Linsol("L", "qr", ca.Sparsity.dense(1, 1), Dict("record_time" => true));
julia> ca.solve(L, ca.DM(2), ca.DM(4)); ca.stats(L)["n_call_solve"]
1
Extra doc: https://github.com/casadi/casadi/wiki/L_2pl
Definition at line 244 of file linsol.cpp.
|
inherited |
Definition at line 105 of file generic_shared_impl.hpp.
|
static |
Definition at line 49 of file linsol.cpp.
|
inlinestatic |
Extra doc: https://github.com/casadi/casadi/wiki/L_1ki
Definition at line 149 of file linsol.hpp.
|
inherited |
Extra doc: https://github.com/casadi/casadi/wiki/L_aw
Definition at line 130 of file generic_shared_impl.hpp.