A simplified interface for NLP modeling/solving. More...
#include <optistack.hpp>
Opti collects decision variables, parameters, an objective and constraints written in natural syntax, builds an nlpsol (or qpsol) instance from them and gives numerical access to the solution. The bookkeeping of flattening variables into one vector and constraints into bounds is hidden.
Workflow:
Opti is stateful: every call above mutates the instance, and the problem is rebuilt lazily at the next solve(). An OptiSol is a copy taken at the time of solve(), so later changes to the Opti do not affect it. Only symbols created by this instance may appear in its expressions; raw MX.sym symbols or symbols of another Opti raise an error.
The constructor argument selects the problem class: "nlp" (default, solved with nlpsol) or "conic" (quadratic programs and SOCPs, solved with qpsol).
An iteration callback can be registered with opti.callback(fh); fh is called with the iteration number after every solver iteration, and opti.debug.value() inside it returns the current iterate. Calling opti.callback() without argument removes it.
>>> opti = Opti()
>>> x = opti.variable()
>>> y = opti.variable()
>>> opti.minimize((y-x**2)**2)
>>> opti.subject_to(x**2+y**2==1)
>>> opti.subject_to(x+y>=1)
>>> opti.solver("ipopt", {"print_time": False}, {"print_level": 0, "sb": "yes"})
>>> sol = opti.solve()
>>> sol.value(x), sol.value(y)
(0.7862, 0.6180)
>>> sol.value(opti.f)
0
>> opti = Opti();
>> x = opti.variable(); y = opti.variable();
>> opti.minimize((y-x^2)^2);
>> opti.subject_to(x^2+y^2==1);
>> opti.subject_to(x+y>=1);
>> opti.solver('ipopt', struct('print_time', false), struct('print_level', 0, 'sb', 'yes'));
>> sol = opti.solve();
>> sol.value(x), sol.value(y)
0.7862
0.6180
>> sol.value(opti.f)
0
julia> opti = ca.Opti();
julia> x = ca.variable(opti);
julia> y = ca.variable(opti);
julia> ca.minimize(opti, (y - x^2)^2)
julia> ca.subject_to(opti, x^2 + y^2 == 1)
julia> ca.subject_to(opti, x + y >= 1)
julia> ca.solver(opti, "ipopt", Dict("print_time" => false),
                  Dict("print_level" => 0, "sb" => "yes"))
julia> sol = ca.solve(opti);
julia> ca.value(sol, x), ca.value(sol, y)
(0.7862, 0.6180)
julia> ca.value(sol, ca.f(opti))
0
Parametric problems are re-solved by changing parameter values:
>>> opti = Opti()
>>> x = opti.variable(2)
>>> p = opti.parameter()
>>> opti.minimize(sumsqr(x-p))
>>> opti.subject_to(1 <= (sum1(x) <= 2))
>>> opti.solver("ipopt", {"print_time": False}, {"print_level": 0, "sb": "yes"})
>>> opti.set_value(p, 3)
>>> sol = opti.solve()
>>> sol.value(sum1(x))
2.0
>>> opti.set_value(p, 0)
>>> sol = opti.solve()
>>> sol.value(sum1(x))
1.0
>> opti = Opti();
>> x = opti.variable(2); p = opti.parameter();
>> opti.minimize(sumsqr(x-p));
>> opti.subject_to(1 <= sum1(x) <= 2);
>> opti.solver('ipopt', struct('print_time', false), struct('print_level', 0, 'sb', 'yes'));
>> opti.set_value(p, 3); sol = opti.solve();
>> sol.value(sum1(x))
2
>> opti.set_value(p, 0); sol = opti.solve();
>> sol.value(sum1(x))
1
julia> opti = ca.Opti();
julia> x = ca.variable(opti, 2);
julia> p = ca.parameter(opti);
julia> ca.minimize(opti, ca.sumsqr(x - p))
julia> ca.subject_to(opti, 1 <= (sum(x) <= 2))
julia> ca.solver(opti, "ipopt", Dict("print_time" => false),
                  Dict("print_level" => 0, "sb" => "yes"))
julia> ca.set_value(opti, p, 3)
julia> sol = ca.solve(opti);
julia> ca.value(sol, sum(x))
2.0
julia> ca.set_value(opti, p, 0)
julia> sol = ca.solve(opti);
julia> ca.value(sol, sum(x))
1.0
An iteration callback:
>>> opti = Opti()
>>> x = opti.variable()
>>> opti.minimize((x-1)**2)
>>> opti.solver("ipopt", {"print_time": False}, {"print_level": 0, "sb": "yes"})
>>> history = []
>>> opti.callback(lambda i: history.append((i, opti.debug.value(x))))
>>> sol = opti.solve()
>>> history
[(0, 0.0), (1, 1.0)]
>>> opti.callback()
>>> sol = opti.solve()
>>> len(history)
2
>> opti = Opti(); x = opti.variable(); opti.minimize((x-1)^2);
>> opti.solver('ipopt', struct('print_time', false), struct('print_level', 0, 'sb', 'yes'));
>> opti.callback(@(i) fprintf('%d %.3f\n', i, opti.debug.value(x)));
>> sol = opti.solve();
0 0.000
1 1.000
>> opti.callback();
>> sol = opti.solve();
julia> opti = ca.Opti();
julia> x = ca.variable(opti);
julia> ca.minimize(opti, (x - 1)^2)
julia> ca.solver(opti, "ipopt", Dict("print_time" => false),
                  Dict("print_level" => 0, "sb" => "yes"))
julia> history = Tuple{Int,Float64}[];
julia> ca.callback(opti, i -> push!(history, (i, ca.value(ca.debug(opti), x))))
julia> sol = ca.solve(opti);
julia> history
2-element Vector{Tuple{Int64, Float64}}:
 (0, 0.0)
 (1, 1.0)
julia> ca.callback(opti)
julia> sol = ca.solve(opti);
julia> length(history)
2
Extra doc: https://github.com/casadi/casadi/wiki/L_16
Definition at line 234 of file optistack.hpp.
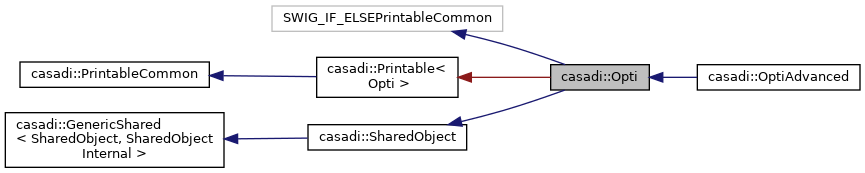
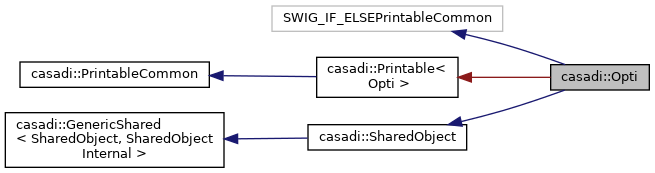
Public Types | |
| using | internal_base_type = SharedObjectInternal |
| using | base_type = SharedObject |
Public Member Functions | |
| Opti (const std::string &problem_type="nlp") | |
| Create an empty Opti context. More... | |
| MX | variable (casadi_int n=1, casadi_int m=1, const std::string &attribute="full") |
| Create a decision variable (symbol) More... | |
| MX | variable (const Sparsity &sp, const std::string &attribute="full") |
| Create a decision variable with a given sparsity pattern; only "full" is supported. More... | |
| MX | variable (const MX &symbol, const std::string &attribute="full") |
| Register an existing MX symbol as a decision variable of this instance. More... | |
| MX | parameter (casadi_int n=1, casadi_int m=1, const std::string &attribute="full") |
| Create a parameter (symbol); fixed during optimization. More... | |
| MX | parameter (const Sparsity &sp, const std::string &attribute="full") |
| Create a parameter with a given sparsity pattern. More... | |
| MX | parameter (const MX &symbol, const std::string &attribute="full") |
| Register an existing MX symbol as a parameter of this instance. More... | |
| void | minimize (const MX &f, double linear_scale=1) |
| Set the objective. More... | |
| void | subject_to () |
| Clear all constraints. More... | |
| void | solver (const std::string &solver, const Dict &plugin_options=Dict(), const Dict &solver_options=Dict()) |
| Select the numerical solver and its options. More... | |
| void | set_domain (const MX &x, const std::string &domain) |
| Set the domain of a decision variable. More... | |
| void | set_linear_scale (const MX &x, const DM &scale, const DM &offset=0) |
| Set the linear scaling of a decision variable. More... | |
| OptiSol | solve () |
| Solve the problem. More... | |
| OptiSol | solve_limited () |
| Solve the problem, accepting a limit as outcome. More... | |
| Dict | stats () const |
| Get the statistics of the last solve. More... | |
| std::string | return_status () const |
| Get the return status of the last solve. More... | |
| std::vector< MX > | initial () const |
| Get assignment expressions for the initial guesses. More... | |
| std::vector< MX > | value_variables () const |
| Get assignment expressions for the latest values. More... | |
| std::vector< MX > | value_parameters () const |
| Function | scale_helper (const Function &h) const |
| Scale a helper function constructed via opti.x, opti.g, ... More... | |
| MX | dual (const MX &m) const |
| Get the dual variable (Lagrange multiplier) of a constraint. More... | |
| casadi_int | nx () const |
| Number of (scalarised) decision variables. More... | |
| casadi_int | np () const |
| Number of (scalarised) parameters. More... | |
| casadi_int | ng () const |
| Number of (scalarised) constraints. More... | |
| MX | x () const |
| Get all (scalarised) decision variables as a symbolic column vector. More... | |
| MX | p () const |
| Get all (scalarised) parameters as a symbolic column vector. More... | |
| MX | g () const |
| Get all (scalarised) constraint expressions as a column vector. More... | |
| MX | f () const |
| Get the objective expression. More... | |
| MX | lbg () const |
| Get all (scalarised) bounds on constraints as a column vector. More... | |
| MX | ubg () const |
| DM | x_linear_scale () const |
| Per-entry scale of x (see set_linear_scale); a Python property. More... | |
| DM | x_linear_scale_offset () const |
| Per-entry offset of x (see set_linear_scale); a Python property. More... | |
| DM | g_linear_scale () const |
| Per-row scale of g (see subject_to); a Python property. More... | |
| double | f_linear_scale () const |
| Scale of the objective (see minimize); a Python property. More... | |
| MX | lam_g () const |
| Get all (scalarised) dual variables as a symbolic column vector. More... | |
| OptiAdvanced | debug () const |
| Get a copy with advanced (debugging) functionality. More... | |
| OptiAdvanced | advanced () const |
| Get a copy with advanced functionality. More... | |
| Opti | copy () const |
| Get a deep copy of the Opti instance. More... | |
| void | update_user_dict (const MX &m, const Dict &meta) |
| Add user data to a symbol or constraint. More... | |
| void | update_user_dict (const std::vector< MX > &m, const Dict &meta) |
| Dict | user_dict (const MX &m) const |
| Get the user data of a symbol or constraint. More... | |
| std::string | type_name () const |
| Readable name of the class. More... | |
| void | disp (std::ostream &stream, bool more=false) const |
| Print a summary of the instance. More... | |
| std::string | get_str (bool more=false) const |
| Get string representation. More... | |
| Opti (const Opti &x) | |
| ~Opti () | |
| Destructor. More... | |
| Opti (OptiNode *node) | |
| std::string | class_name () const |
| Get class name. More... | |
| void | print_ptr (std::ostream &stream=casadi::uout()) const |
| void | own (SharedObjectInternal *node) |
| void | assign (SharedObjectInternal *node) |
| Assign the node to a node class pointer without reference counting. More... | |
| SharedObjectInternal * | get () const |
| Get a const pointer to the node. More... | |
| casadi_int | getCount () const |
| Get the reference count. More... | |
| void | swap (GenericShared &other) |
| Swap content with another instance. More... | |
| std::string | debug_repr () const |
| bool | is_null () const |
| Is a null pointer? More... | |
| casadi_int | __hash__ () const |
| Returns a number that is unique for a given Node. More... | |
| GenericWeakRef< SharedObject, SharedObjectInternal > * | weak () |
| Get a weak reference to the object. More... | |
| void | subject_to (const MX &g, const Dict &options=Dict()) |
| Add constraints. More... | |
| void | subject_to (const std::vector< MX > &g, const Dict &options=Dict()) |
| Add constraints. More... | |
| void | subject_to (const MX &g, const DM &linear_scale, const Dict &options=Dict()) |
| Add constraints. More... | |
| void | subject_to (const std::vector< MX > &g, const DM &linear_scale, const Dict &options=Dict()) |
| Add constraints. More... | |
| void | set_initial (const MX &x, const DM &v) |
| Set the initial guess of decision variables or dual variables. More... | |
| void | set_initial (const std::vector< MX > &assignments) |
| Set the initial guess of decision variables or dual variables. More... | |
| void | set_value (const MX &x, const DM &v) |
| Set the value of a parameter. More... | |
| void | set_value (const std::vector< MX > &assignments) |
| Set the value of a parameter. More... | |
| native_DM | value (const MX &x, const std::vector< MX > &values=std::vector< MX >()) const |
| Evaluate an expression at the current values. More... | |
| native_DM | value (const DM &x, const std::vector< MX > &values=std::vector< MX >()) const |
| Evaluate an expression at the current values. More... | |
| native_DM | value (const SX &x, const std::vector< MX > &values=std::vector< MX >()) const |
| Evaluate an expression at the current values. More... | |
| Function | to_function (const std::string &name, const std::vector< MX > &args, const std::vector< MX > &res, const Dict &opts=Dict()) |
| Create a CasADi Function from the Opti solver. More... | |
| Function | to_function (const std::string &name, const std::vector< MX > &args, const std::vector< MX > &res, const std::vector< std::string > &name_in, const std::vector< std::string > &name_out, const Dict &opts=Dict()) |
| Create a CasADi Function from the Opti solver. More... | |
| Function | to_function (const std::string &name, const std::map< std::string, MX > &dict, const std::vector< std::string > &name_in, const std::vector< std::string > &name_out, const Dict &opts=Dict()) |
| Same, with inputs and outputs picked by name from a dict of expressions. More... | |
| void | callback_class (OptiCallback *callback) |
| Helper methods for callback() More... | |
| void | callback_class () |
| Helper methods for callback() More... | |
| OptiNode * | operator-> () |
| Access a member of the node. More... | |
| const OptiNode * | operator-> () const |
| Const access a member of the node. More... | |
Static Public Member Functions | |
| static MX | bounded (const MX &lb, const MX &expr, const MX &ub) |
| Construct a double inequality. More... | |
| static Opti | create (OptiNode *node) |
Protected Member Functions | |
| void | count_up () |
| void | count_down () |
Friends | |
| class | InternalOptiCallback |
|
inherited |
Definition at line 103 of file shared_object.hpp.
|
inherited |
Definition at line 102 of file shared_object.hpp.
| casadi::Opti::Opti | ( | const std::string & | problem_type = "nlp" | ) |
| problem_type | "nlp" (default): general nonlinear program, solved with an nlpsol plugin. "conic": quadratic program or SOCP, solved with a qpsol plugin; the objective must then be quadratic and the constraints linear or second-order cone. Any other string raises an error. |
>>> opti = Opti()
>>> opti.nx, opti.np, opti.ng
(0, 0, 0)
>>> opti = Opti("conic")
>>> x = opti.variable(2)
>>> opti.minimize(sumsqr(x-1))
>>> opti.subject_to(x[0]+x[1] <= 1)
>>> opti.solver("qrqp", {"print_time": False, "print_iter": False,
...                      "print_header": False, "print_info": False})
>>> opti.solve().value(x)
array([0.5, 0.5])
>>> try:
...   Opti("lp")
... except Exception as e:
...   print(str(e).splitlines()[-1])
Specified problem type 'lp'unknown. Choose 'nlp' (default) or 'conic'.
>> opti = Opti(); fprintf('%d %d %d\n', opti.nx, opti.np, opti.ng)
0 0 0
>> opti = Opti('conic'); x = opti.variable(2);
>> opti.minimize(sumsqr(x-1)); opti.subject_to(x(1)+x(2) <= 1);
>> opts = struct('print_time', false, 'print_iter', false, 'print_header', false);
>> opts.print_info = false; opti.solver('qrqp', opts);
>> sol = opti.solve(); disp(sol.value(x)')
0.5000 0.5000
>> try, Opti('lp'); catch e, disp(contains(e.message, 'Specified problem type')); end
1
julia> opti = ca.Opti();
julia> ca.nx(opti), ca.np(opti), ca.ng(opti)
(0, 0, 0)
julia> opti = ca.Opti("conic");
julia> x = ca.variable(opti, 2);
julia> ca.minimize(opti, ca.sumsqr(x - 1))
julia> ca.subject_to(opti, x[1] + x[2] <= 1)
julia> ca.solver(opti, "qrqp", Dict("print_time" => false, "print_iter" => false,
                                     "print_header" => false, "print_info" => false))
julia> ca.value(ca.solve(opti), x)
2-element Vector{Float64}:
 0.5
 0.5
julia> try
           ca.Opti("lp")
       catch e
           println(last(split(sprint(showerror, e), "\n")))
       end
Specified problem type 'lp'unknown. Choose 'nlp' (default) or 'conic'.
Extra doc: https://github.com/casadi/casadi/wiki/L_17
Definition at line 47 of file optistack.cpp.
References casadi::OptiNode::create(), and casadi::GenericShared< SharedObject, SharedObjectInternal >::own().
Referenced by create().
| casadi::Opti::Opti | ( | const Opti & | x | ) |
Definition at line 79 of file optistack.cpp.
References callback_class().
|
inline |
Extra doc: https://github.com/casadi/casadi/wiki/L_1q
Definition at line 2678 of file optistack.hpp.
| casadi::Opti::Opti | ( | OptiNode * | node | ) |
Definition at line 75 of file optistack.cpp.
References casadi::GenericShared< SharedObject, SharedObjectInternal >::own().
|
inherited |
If the Object does not point to any node, "0" is returned.
Extra doc: https://github.com/casadi/casadi/wiki/L_av
Definition at line 123 of file generic_shared_impl.hpp.
| OptiAdvanced casadi::Opti::advanced | ( | ) | const |
Same as debug(); the name signals use of the unstable OptiAdvanced API rather than debugging. In Python this is a read-only property.
>>> opti = Opti()
>>> x = opti.variable()
>>> opti.minimize(x**2)
>>> print(opti.advanced.symvar())
[MX(opti..._x_1)]
>> opti = Opti(); x = opti.variable(); opti.minimize(x^2);
>> sv = opti.advanced.symvar(); disp(numel(sv)), disp(sv{1})
1
opti..._x_1
julia> opti = ca.Opti();
julia> x = ca.variable(opti);
julia> ca.minimize(opti, x^2)
julia> print(ca.symvar(ca.advanced(opti)))
MX[opti..._x_1]
Extra doc: https://github.com/casadi/casadi/wiki/L_1m
Definition at line 854 of file optistack.cpp.
References copy().
|
inherited |
improper use will cause memory leaks!
Extra doc: https://github.com/casadi/casadi/wiki/L_at
Definition at line 96 of file generic_shared_impl.hpp.
Returns the expression (lb <= expr) <= ub, which subject_to() recognizes as a double-bounded constraint lb <= expr <= ub when lb and ub are free of decision variables. Identical to writing lb <= (expr <= ub) by hand; provided because Python's chained comparison lb <= expr <= ub raises an error for MX. A static method; the instance is not needed.
>>> opti = Opti()
>>> x = opti.variable(2)
>>> opti.subject_to(opti.bounded(-1, x, 1))
>>> opti.subject_to(Opti.bounded(0, x[0] + x[1], 1))
>>> opti.ng, opti.lbg, opti.ubg
(3, MX(vertcat(all_-1(2x1), 0)), MX(ones(3x1)))
julia> opti = ca.Opti();
julia> x = ca.variable(opti, 2);
julia> ca.subject_to(opti, ca.bounded(-1, x, 1))
julia> ca.subject_to(opti, ca.Opti.bounded(0, x[1] + x[2], 1))
julia> ca.ng(opti), ca.lbg(opti), ca.ubg(opti)
(3, vertcat(all_-1(2x1), 0), ones(3x1))
Extra doc: https://github.com/casadi/casadi/wiki/L_1k
Definition at line 2353 of file optistack.hpp.
| void casadi::Opti::callback_class | ( | ) |
Do not use directly; use opti.callback(fh) in Python/MATLAB, which wraps a callable in an OptiCallback and registers it here. The no-argument form removes the callback.
Extra doc: https://github.com/casadi/casadi/wiki/L_1p
Definition at line 475 of file optistack.cpp.
Referenced by Opti().
| void casadi::Opti::callback_class | ( | OptiCallback * | callback | ) |
Do not use directly; use opti.callback(fh) in Python/MATLAB, which wraps a callable in an OptiCallback and registers it here. The no-argument form removes the callback.
Extra doc: https://github.com/casadi/casadi/wiki/L_1p
Definition at line 467 of file optistack.cpp.
|
inherited |
Extra doc: https://github.com/casadi/casadi/wiki/L_au
Definition at line 31 of file shared_object.cpp.
Referenced by casadi::FmuFunction::check_mem_count(), casadi::MXFunction::export_code_body(), and casadi::BlazingSplineFunction::merge().
| Opti casadi::Opti::copy | ( | ) | const |
The copy shares the symbols (so expressions in them stay valid for both) but has its own constraints, values, initial guesses and solver state. Updating the copy does not update the original.
>>> opti = Opti()
>>> x = opti.variable()
>>> opti.minimize(x**2)
>>> opti2 = opti.copy()
>>> opti2.subject_to(x >= 2)
>>> opti.ng, opti2.ng
(0, 1)
>> opti = Opti(); x = opti.variable(); opti.minimize(x^2);
>> opti2 = opti.copy(); opti2.subject_to(x >= 2); fprintf('%d %d\n', opti.ng, opti2.ng)
0 1
julia> opti = ca.Opti();
julia> x = ca.variable(opti);
julia> ca.minimize(opti, x^2)
julia> opti2 = opti.copy();
julia> ca.subject_to(opti2, x >= 2)
julia> ca.ng(opti), ca.ng(opti2)
(0, 1)
Extra doc: https://github.com/casadi/casadi/wiki/L_1n
Definition at line 857 of file optistack.cpp.
References casadi::OptiNode::copy().
Referenced by advanced(), and debug().
|
protectedinherited |
Definition at line 133 of file generic_shared_impl.hpp.
|
protectedinherited |
Definition at line 132 of file generic_shared_impl.hpp.
Definition at line 86 of file optistack.cpp.
References Opti().
Referenced by casadi::OptiNode::copy().
| OptiAdvanced casadi::Opti::debug | ( | ) | const |
Returns an OptiAdvanced deep copy of the current state: same symbols, constraints, values and latest solver result, with extra methods such as value() at a non-converged iterate, show_infeasibilities(), x_describe()/g_describe() and casadi_solver(). Changes to the copy do not affect the original. No API stability is guaranteed for the extra methods. In Python this is a read-only property: opti.debug.value(x).
>>> opti = Opti()
>>> x = opti.variable()
>>> opti.minimize((x-1)**6)
>>> opti.solver("ipopt", {"print_time": False},
...             {"print_level": 0, "max_iter": 2, "sb": "yes"})
>>> try:
...   opti.solve()
... except Exception as e:
...   pass
>>> opti.debug.value(x)
0.36
>>> print(opti.debug.x_describe(0))
Opti decision variable 'opti..._x_1' of shape 1x1, called from ...
>> opti = Opti(); x = opti.variable(); opti.minimize((x-1)^6);
>> ipopt = struct('print_level', 0, 'max_iter', 2, 'sb', 'yes');
>> opti.solver('ipopt', struct('print_time', false), ipopt);
>> try, opti.solve(); catch e, end
>> opti.debug.value(x)
0.36
>> opti.debug.x_describe(1)
Opti decision variable 'opti..._x_1' of shape 1x1, called from ...
julia> opti = ca.Opti();
julia> x = ca.variable(opti);
julia> ca.minimize(opti, (x - 1)^6)
julia> ca.solver(opti, "ipopt", Dict("print_time" => false),
                  Dict("print_level" => 0, "max_iter" => 2, "sb" => "yes"))
julia> try
           ca.solve(opti)
       catch e
       end
julia> ca.value(ca.debug(opti), x)
0.36
julia> print(ca.x_describe(ca.debug(opti), 0))
Opti decision variable 'opti..._x_1' of shape 1x1, called from ...
Extra doc: https://github.com/casadi/casadi/wiki/L_1l
Definition at line 851 of file optistack.cpp.
References copy().
Referenced by disp().
|
inherited |
Definition at line 112 of file generic_shared_impl.hpp.
| void casadi::Opti::disp | ( | std::ostream & | stream, |
| bool | more = false |
||
| ) | const |
Shows the instance number, the number of variables, parameters and constraints that appear in the problem, whether the solver is up to date and the last return status.
>>> opti = Opti()
>>> x = opti.variable(2)
>>> opti.minimize(sumsqr(x))
>>> opti.subject_to(x[0] >= 1)
>>> print(opti)
Opti {
  instance #...
  #variables: 1 (nx = 2)
  #parameters: 0 (np = 0)
  #constraints: 1 (ng = 1)
  CasADi solver needs updating.
}
>> opti = Opti(); x = opti.variable(2);
>> opti.minimize(sumsqr(x)); opti.subject_to(x(1) >= 1); disp(opti)
Opti {
  instance #...
  #variables: 1 (nx = 2)
  #parameters: 0 (np = 0)
  #constraints: 1 (ng = 1)
  CasADi solver needs updating.
}
julia> opti = ca.Opti();
julia> x = ca.variable(opti, 2);
julia> ca.minimize(opti, ca.sumsqr(x))
julia> ca.subject_to(opti, x[1] >= 1)
julia> opti
Opti(Opti {
  instance #45
  #variables: 1 (nx = 2)
  #parameters: 0 (np = 0)
  #constraints: 1 (ng = 1)
  CasADi solver needs updating.
})
Extra doc: https://github.com/casadi/casadi/wiki/L_2mx
Definition at line 754 of file optistack.cpp.
References casadi::OptiAdvanced::active_symvar(), casadi::OptiAdvanced::bake(), debug(), casadi::OptiAdvanced::instance_number(), ng(), np(), nx(), casadi::OPTI_DUAL_G, casadi::OPTI_PAR, casadi::OPTI_VAR, casadi::OptiAdvanced::problem_dirty(), return_status(), casadi::OptiAdvanced::solved(), and casadi::OptiAdvanced::solver_dirty().
Referenced by casadi::OptiSol::disp(), and get_str().
m must be the exact expression object that was passed to subject_to(). The result is symbolic; evaluate it with value(). For inequality constraints the dual is nonnegative (the sign of lam_g is removed); for equality constraints it equals the corresponding entries of lam_g. Keep a reference to the constraint expression when you need its dual later.
>>> opti = Opti()
>>> x = opti.variable()
>>> opti.minimize((x-3)**2)
>>> con = x <= 1
>>> opti.subject_to(con)
>>> opti.solver("ipopt", {"print_time": False}, {"print_level": 0, "sb": "yes"})
>>> sol = opti.solve()
>>> sol.value(opti.dual(con)), sol.value(opti.lam_g)
(4.0, 4.0)
>>> opti.subject_to()
>>> con = x >= 4
>>> opti.subject_to(con)
>>> sol = opti.solve()
>>> sol.value(opti.dual(con)), sol.value(opti.lam_g)
(2.0, -2.0)
>>> try:
...   opti.dual(x >= 4)
... except Exception as e:
...   print(str(e).splitlines()[-1])
Constraint not present in Opti stack.
>> opti = Opti(); x = opti.variable(); opti.minimize((x-3)^2);
>> con = x <= 1; opti.subject_to(con);
>> opti.solver('ipopt', struct('print_time', false), struct('print_level', 0, 'sb', 'yes'));
>> sol = opti.solve();
>> sol.value(opti.dual(con)), sol.value(opti.lam_g)
4
4
>> opti.subject_to(); con = x >= 4; opti.subject_to(con); sol = opti.solve();
>> sol.value(opti.dual(con)), sol.value(opti.lam_g)
2
-2
>> try, opti.dual(x >= 4); catch e, disp(contains(e.message, 'Constraint not present')); end
1
julia> opti = ca.Opti();
julia> x = ca.variable(opti);
julia> ca.minimize(opti, (x - 3)^2)
julia> con = x <= 1;
julia> ca.subject_to(opti, con)
julia> ca.solver(opti, "ipopt", Dict("print_time" => false),
                  Dict("print_level" => 0, "sb" => "yes"))
julia> sol = ca.solve(opti);
julia> ca.value(sol, ca.dual(opti, con))
4.0
julia> ca.value(sol, ca.lam_g(opti))
4.0
julia> ca.subject_to(opti)
julia> con = x >= 4;
julia> ca.subject_to(opti, con)
julia> sol = ca.solve(opti);
julia> ca.value(sol, ca.dual(opti, con))
2.0
julia> ca.value(sol, ca.lam_g(opti))
-2.0
julia> try
           ca.dual(opti, x >= 4)
       catch e
           println(last(split(sprint(showerror, e), "\n")))
       end
Constraint not present in Opti stack.
Extra doc: https://github.com/casadi/casadi/wiki/L_1h
Definition at line 302 of file optistack.cpp.
| MX casadi::Opti::f | ( | ) | const |
In Python this is a read-only property.
>>> opti = Opti()
>>> x = opti.variable()
>>> opti.f
MX(0)
>>> opti.minimize(x**2)
>>> print(opti.f)
sq(opti..._x_1)
>> opti = Opti(); x = opti.variable(); disp(opti.f)
0
>> opti.minimize(x^2); disp(opti.f)
sq(opti..._x_1)
julia> opti = ca.Opti();
julia> x = ca.variable(opti);
julia> ca.f(opti)
MX(0)
julia> ca.minimize(opti, x^2)
julia> ca.f(opti)
MX(sq(opti34_x_1))
Extra doc: https://github.com/casadi/casadi/wiki/L_26e
Definition at line 358 of file optistack.cpp.
Referenced by minimize(), and casadi::OptiAdvanced::objective().
| double casadi::Opti::f_linear_scale | ( | ) | const |
Definition at line 415 of file optistack.cpp.
| MX casadi::Opti::g | ( | ) | const |
The expression g passed to the solver, with lbg <= g <= ubg. In Python this is a read-only property.
>>> opti = Opti()
>>> x = opti.variable()
>>> opti.subject_to(x >= 1)
>>> opti.subject_to(x**2 == 4)
>>> opti.minimize(x)
>>> print(opti.g)
vertcat(opti..._x_1, sq(opti..._x_1))
>> opti = Opti(); x = opti.variable();
>> opti.subject_to(x >= 1); opti.subject_to(x^2 == 4); opti.minimize(x);
>> opti.g
vertcat(opti..._x_1, sq(opti..._x_1))
julia> opti = ca.Opti();
julia> x = ca.variable(opti);
julia> ca.subject_to(opti, x >= 1)
julia> ca.subject_to(opti, x^2 == 4)
julia> ca.minimize(opti, x)
julia> ca.g(opti)
MX(vertcat(opti33_x_1, sq(opti33_x_1)))
Extra doc: https://github.com/casadi/casadi/wiki/L_26d
Definition at line 350 of file optistack.cpp.
Referenced by subject_to().
| DM casadi::Opti::g_linear_scale | ( | ) | const |
Definition at line 407 of file optistack.cpp.
|
inherited |
Definition at line 99 of file generic_shared_impl.hpp.
| std::string casadi::Opti::get_str | ( | bool | more = false | ) | const |
Definition at line 776 of file optistack.cpp.
References disp().
Referenced by casadi::OptiSol::get_str().
|
inherited |
Definition at line 102 of file generic_shared_impl.hpp.
| std::vector< MX > casadi::Opti::initial | ( | ) | const |
One expression value==var per variable and dual variable, holding the current initial guess. Pass the list to value() to evaluate an expression at the initial guess, or to set_initial() of another Opti instance with the same symbols.
>>> opti = Opti()
>>> x = opti.variable()
>>> opti.set_initial(x, 2)
>>> opti.minimize(x**2)
>>> print(opti.initial())
[MX((2==opti..._x_1))]
>>> opti.value(x**2+1, opti.initial())
5.0
>> opti = Opti(); x = opti.variable(); opti.set_initial(x, 2); opti.minimize(x^2);
>> ini = opti.initial(); disp(ini{1})
(2==opti..._x_1)
>> opti.value(x^2+1, opti.initial())
5
julia> opti = ca.Opti();
julia> x = ca.variable(opti);
julia> ca.set_initial(opti, x, 2)
julia> ca.minimize(opti, x^2)
julia> print(ca.initial(opti))
MX[(2==opti..._x_1)]
julia> opti.value(x^2 + 1, ca.initial(opti))
5.0
Extra doc: https://github.com/casadi/casadi/wiki/L_266
Definition at line 278 of file optistack.cpp.
|
inherited |
Definition at line 116 of file generic_shared_impl.hpp.
| MX casadi::Opti::lam_g | ( | ) | const |
One multiplier per row of g(), as the solver reports them: with Lagrangian f + lam_g'*g, an entry is positive when the upper bound is active and negative when the lower bound is active, and -lam_g is the sensitivity of the optimal objective to the active bound. Useful for the Lagrangian Hessian, warm starting (set_initial) and as input or output of to_function(). In Python this is a read-only property.
>>> opti = Opti()
>>> x = opti.variable()
>>> p = opti.parameter()
>>> opti.minimize(x**2)
>>> opti.subject_to(x >= p)
>>> opti.set_value(p, 1)
>>> opti.solver("ipopt", {"print_time": False}, {"print_level": 0, "sb": "yes"})
>>> sol = opti.solve()
>>> sol.value(opti.lam_g)
-2.0
>>> sol.value(hessian(opti.f + dot(opti.lam_g, opti.g), opti.x)[0])
2.0
>> opti = Opti(); x = opti.variable(); p = opti.parameter();
>> opti.minimize(x^2); opti.subject_to(x >= p); opti.set_value(p, 1);
>> opti.solver('ipopt', struct('print_time', false), struct('print_level', 0, 'sb', 'yes'));
>> sol = opti.solve(); disp(sol.value(opti.lam_g))
-2
>> H = hessian(opti.f + dot(opti.lam_g, opti.g), opti.x); disp(sol.value(H))
2
julia> opti = ca.Opti();
julia> x = ca.variable(opti);
julia> p = ca.parameter(opti);
julia> ca.minimize(opti, x^2)
julia> ca.subject_to(opti, x >= p)
julia> ca.set_value(opti, p, 1)
julia> ca.solver(opti, "ipopt", Dict("print_time" => false),
                  Dict("print_level" => 0, "sb" => "yes"))
julia> sol = ca.solve(opti);
julia> ca.value(sol, ca.lam_g(opti))
-2.0
julia> L = ca.f(opti) + ca.dot(ca.lam_g(opti), ca.g(opti));
julia> ca.value(sol, ca.hessian(L, ca.x(opti))[1])
2.0
Extra doc: https://github.com/casadi/casadi/wiki/L_1i
Definition at line 383 of file optistack.cpp.
| MX casadi::Opti::lbg | ( | ) | const |
lbg() and ubg() are the lower and upper bounds matching g(); they are expressions in the parameters (constants otherwise), with -inf/inf for one-sided constraints. In Python these are read-only properties.
>>> opti = Opti()
>>> x = opti.variable()
>>> p = opti.parameter()
>>> opti.subject_to(x >= 1)
>>> opti.subject_to(x <= p)
>>> opti.subject_to(x**2 == 4)
>>> opti.minimize(x)
>>> print(opti.lbg, opti.ubg)
vertcat(1, -inf, 4) vertcat(inf, opti..._p_1, 4)
>> opti = Opti(); x = opti.variable(); p = opti.parameter();
>> opti.subject_to(x >= 1); opti.subject_to(x <= p); opti.subject_to(x^2 == 4);
>> opti.minimize(x); disp(opti.lbg), disp(opti.ubg)
vertcat(1, -inf, 4)
vertcat(inf, opti..._p_1, 4)
julia> opti = ca.Opti();
julia> x = ca.variable(opti);
julia> p = ca.parameter(opti);
julia> ca.subject_to(opti, x >= 1)
julia> ca.subject_to(opti, x <= p)
julia> ca.subject_to(opti, x^2 == 4)
julia> ca.minimize(opti, x)
julia> print(ca.lbg(opti), " ", ca.ubg(opti))
vertcat(1, -inf, 4) vertcat(inf, opti..._p_1, 4)
Extra doc: https://github.com/casadi/casadi/wiki/L_26f
Definition at line 366 of file optistack.cpp.
| void casadi::Opti::minimize | ( | const MX & | f, |
| double | linear_scale = 1 |
||
| ) |
The objective must be a scalar expression in the variables and parameters of this instance; a non-scalar raises an error. The default objective is 0. Each call replaces the previous objective. Dual variables (opti.dual, opti.lam_g) may not appear in it.
| f | Scalar MX expression to minimize |
| linear_scale | The solver sees f divided by this factor (default 1) |
>>> opti = Opti()
>>> x = opti.variable(2)
>>> opti.minimize(sumsqr(x))
>>> opti.minimize(x[0]**2, 2)
>>> print(opti.f, opti.f_linear_scale)
sq(opti..._x_1[0]) 2.0
>>> try:
...   opti.minimize(x)
... except Exception as e:
...   print(str(e).splitlines()[-1])
Objective must be scalar, got 2x1.
>> opti = Opti(); x = opti.variable(2);
>> opti.minimize(sumsqr(x)); opti.minimize(x(1)^2, 2);
>> opti.f, opti.f_linear_scale
sq(opti..._x_1[0])
2
>> try, opti.minimize(x); catch e, disp(contains(e.message, 'Objective must be scalar')); end
1
julia> opti = ca.Opti();
julia> x = ca.variable(opti, 2);
julia> ca.minimize(opti, ca.sumsqr(x))
julia> opti.minimize(x[1]^2, 2)
julia> print(ca.f(opti), " ", ca.f_linear_scale(opti))
sq(opti..._x_1[0]) 2.0
julia> try
           ca.minimize(opti, x)
       catch e
           println(last(split(sprint(showerror, e), "\n")))
       end
Objective must be scalar, got 2x1.
Extra doc: https://github.com/casadi/casadi/wiki/L_1a
Definition at line 114 of file optistack.cpp.
References f().
| casadi_int casadi::Opti::ng | ( | ) | const |
Total number of constraint rows; a double-bounded constraint counts once. In Python this is a read-only property.
>>> opti = Opti()
>>> x = opti.variable(2)
>>> opti.subject_to(0 <= (x <= 1))
>>> opti.subject_to(x[0] == x[1])
>>> opti.ng
3
>> opti = Opti(); x = opti.variable(2);
>> opti.subject_to(0 <= x <= 1); opti.subject_to(x(1) == x(2)); disp(opti.ng)
3
julia> opti = ca.Opti();
julia> x = ca.variable(opti, 2);
julia> ca.subject_to(opti, 0 <= (x <= 1))
julia> ca.subject_to(opti, x[1] == x[2])
julia> ca.ng(opti)
3
Extra doc: https://github.com/casadi/casadi/wiki/L_26a
Definition at line 326 of file optistack.cpp.
Referenced by disp().
| casadi_int casadi::Opti::np | ( | ) | const |
Counts the nonzeros of all parameters that appear in the problem. In Python this is a read-only property.
>>> opti = Opti()
>>> x = opti.variable()
>>> p = opti.parameter(2, 2)
>>> opti.minimize(x*sum1(vec(p)))
>>> opti.np
4
>> opti = Opti(); x = opti.variable(); p = opti.parameter(2, 2);
>> opti.minimize(x*sum1(vec(p))); disp(opti.np)
4
julia> opti = ca.Opti();
julia> x = ca.variable(opti);
julia> p = ca.parameter(opti, 2, 2);
julia> ca.minimize(opti, x*sum(vec(p)))
julia> ca.np(opti)
4
Extra doc: https://github.com/casadi/casadi/wiki/L_269
Definition at line 318 of file optistack.cpp.
Referenced by disp().
| casadi_int casadi::Opti::nx | ( | ) | const |
Counts the nonzeros of all variables that appear in the objective or constraints. In Python this is a read-only property.
>>> opti = Opti()
>>> x = opti.variable(3)
>>> y = opti.variable()
>>> opti.minimize(sumsqr(x))
>>> opti.nx
3
>> opti = Opti(); x = opti.variable(3); y = opti.variable();
>> opti.minimize(sumsqr(x)); disp(opti.nx)
3
julia> opti = ca.Opti();
julia> x = ca.variable(opti, 3);
julia> y = ca.variable(opti);
julia> ca.minimize(opti, ca.sumsqr(x))
julia> ca.nx(opti)
3
Extra doc: https://github.com/casadi/casadi/wiki/L_268
Definition at line 310 of file optistack.cpp.
Referenced by disp().
| OptiNode * casadi::Opti::operator-> | ( | ) |
Extra doc: https://github.com/casadi/casadi/wiki/L_1r
Definition at line 38 of file optistack.cpp.
References casadi::GenericShared< SharedObject, SharedObjectInternal >::operator->().
| const OptiNode * casadi::Opti::operator-> | ( | ) | const |
Extra doc: https://github.com/casadi/casadi/wiki/L_1s
Definition at line 42 of file optistack.cpp.
References casadi::GenericShared< SharedObject, SharedObjectInternal >::operator->().
|
inherited |
Assign the node to a node class pointer (or null)
Definition at line 89 of file generic_shared_impl.hpp.
| MX casadi::Opti::p | ( | ) | const |
Restricted to the parameters that appear in the problem. In Python this is a read-only property.
>>> opti = Opti()
>>> x = opti.variable()
>>> p = opti.parameter(2)
>>> opti.minimize(x*p[0])
>>> opti.p.shape
(2, 1)
>> opti = Opti(); x = opti.variable(); p = opti.parameter(2);
>> opti.minimize(x*p(1)); disp(size(opti.p))
2 1
julia> opti = ca.Opti();
julia> x = ca.variable(opti);
julia> p = ca.parameter(opti, 2);
julia> ca.minimize(opti, x*p[1])
julia> size(ca.p(opti))
(2, 1)
Extra doc: https://github.com/casadi/casadi/wiki/L_26c
Definition at line 342 of file optistack.cpp.
| MX casadi::Opti::parameter | ( | casadi_int | n = 1, |
| casadi_int | m = 1, |
||
| const std::string & | attribute = "full" |
||
| ) |
Returns an MX symbol that is held constant by the solver. Each parameter that appears in the problem must be given a numerical value with set_value() before solve(), otherwise solve() raises an error naming the parameter. The order of creation does not matter for the result.
| n | Number of rows (default 1) |
| m | Number of columns (default 1) |
| attribute | "full" (default) or "symmetric" |
>>> opti = Opti()
>>> x = opti.variable()
>>> p = opti.parameter(2)
>>> opti.minimize(sumsqr(x-p))
>>> opti.solver("ipopt", {"print_time": False}, {"print_level": 0, "sb": "yes"})
>>> try:
...   opti.solve()
... except Exception as e:
...   print(str(e).splitlines()[-2])
You have forgotten to assign a value to a parameter ('set_value'), or have set it to NaN/Inf:
>>> opti.set_value(p, [1, 3])
>>> opti.solve().value(x)
2.0
>> opti = Opti(); x = opti.variable(); p = opti.parameter(2);
>> opti.minimize(sumsqr(x-p));
>> opti.solver('ipopt', struct('print_time', false), struct('print_level', 0, 'sb', 'yes'));
>> try, opti.solve(); catch e, disp(contains(e.message, 'forgotten to assign a value')); end
1
>> opti.set_value(p, [1; 3]); sol = opti.solve(); disp(sol.value(x))
2
julia> opti = ca.Opti();
julia> x = ca.variable(opti);
julia> p = ca.parameter(opti, 2);
julia> ca.minimize(opti, ca.sumsqr(x - p))
julia> ca.solver(opti, "ipopt", Dict("print_time" => false),
                  Dict("print_level" => 0, "sb" => "yes"))
julia> try
           ca.solve(opti)
       catch e
           println(split(sprint(showerror, e), "\n")[end-1])
       end
You have forgotten to assign a value to a parameter ('set_value'), or have set it to NaN/Inf:
julia> ca.set_value(opti, p, [1, 3])
julia> ca.value(ca.solve(opti), x)
2.0
Extra doc: https://github.com/casadi/casadi/wiki/L_19
Definition at line 90 of file optistack.cpp.
Definition at line 106 of file optistack.cpp.
Definition at line 98 of file optistack.cpp.
|
inherited |
Print the pointer to the internal class
Definition at line 43 of file shared_object.cpp.
References casadi::GenericShared< SharedObject, SharedObjectInternal >::get().
| std::string casadi::Opti::return_status | ( | ) | const |
The plugin's "return_status" string (e.g. "Solve_Succeeded" or "Infeasible_Problem_Detected" for Ipopt), or "unknown" when no solve has happened. No stability is guaranteed for the strings.
>>> opti = Opti()
>>> x = opti.variable()
>>> opti.minimize(x**2)
>>> opti.return_status()
'unknown'
>>> opti.subject_to(x >= 1)
>>> opti.subject_to(x <= -1)
>>> opti.solver("ipopt", {"print_time": False}, {"print_level": 0, "sb": "yes"})
>>> try:
...   opti.solve()
... except Exception as e:
...   print(opti.return_status())
Infeasible_Problem_Detected
>> opti = Opti(); x = opti.variable(); opti.minimize(x^2);
>> opti.return_status()
unknown
>> opti.subject_to(x >= 1); opti.subject_to(x <= -1);
>> opti.solver('ipopt', struct('print_time', false), struct('print_level', 0, 'sb', 'yes'));
>> try, opti.solve(); catch e, disp(opti.return_status()); end
Infeasible_Problem_Detected
julia> opti = ca.Opti();
julia> x = ca.variable(opti);
julia> ca.minimize(opti, x^2)
julia> ca.return_status(opti)
"unknown"
julia> ca.subject_to(opti, x >= 1)
julia> ca.subject_to(opti, x <= -1)
julia> ca.solver(opti, "ipopt", Dict("print_time" => false),
                  Dict("print_level" => 0, "sb" => "yes"))
julia> try
           ca.solve(opti)
       catch e
           println(ca.return_status(opti))
       end
Infeasible_Problem_Detected
Extra doc: https://github.com/casadi/casadi/wiki/L_1g
Definition at line 270 of file optistack.cpp.
Referenced by disp().
Wraps a user-written derivative function so that it operates in the scaled space the solver sees (set_linear_scale(), minimize()/subject_to() scales). h must be named "nlp_jac_g" (inputs x, p; outputs g, jac_g_x) or "nlp_hess_l" (inputs x, p, lam_f, lam_g; output the Lagrangian Hessian); other names raise an error. The result can be handed to a solver that accepts custom derivative functions.
>>> opti = Opti()
>>> x = opti.variable()
>>> p = opti.parameter()
>>> opti.set_linear_scale(x, 2, 1)
>>> opti.minimize((x-p)**2)
>>> opti.subject_to(x >= 0)
>>> h = Function("nlp_jac_g", [opti.x, opti.p], [opti.g, jacobian(opti.g, opti.x)],
...              ["x", "p"], ["g", "jac_g_x"])
>>> hs = opti.scale_helper(h)
>>> hs(x=3, p=0)
{'g': DM(7), 'jac_g_x': DM(2)}
>> opti = Opti(); x = opti.variable(); p = opti.parameter();
>> opti.set_linear_scale(x, 2, 1); opti.minimize((x-p)^2); opti.subject_to(x >= 0);
>> J = jacobian(opti.g, opti.x);
>> h = Function('nlp_jac_g', {opti.x, opti.p}, {opti.g, J}, {'x', 'p'}, {'g', 'jac_g_x'});
>> hs = opti.scale_helper(h); r = hs('x', 3, 'p', 0); disp(r.g), disp(r.jac_g_x)
7
2
julia> opti = ca.Opti();
julia> x = ca.variable(opti);
julia> p = ca.parameter(opti);
julia> ca.set_linear_scale(opti, x, 2, 1)
julia> ca.minimize(opti, (x - p)^2)
julia> ca.subject_to(opti, x >= 0)
julia> g, X = ca.g(opti), ca.x(opti);
julia> h = ca.Function("nlp_jac_g", [X, ca.p(opti)], [g, ca.jacobian(g, X)],
                       ["x", "p"], ["g", "jac_g_x"]);
julia> hs = ca.scale_helper(opti, h);
julia> hs(x=3, p=0)
Dict{String, DM} with 2 entries:
  "g" => 7
  "jac_g_x" => 2
Extra doc: https://github.com/casadi/casadi/wiki/L_2ci
Definition at line 254 of file optistack.cpp.
Referenced by casadi::OptiNode::scale_helper().
| void casadi::Opti::set_domain | ( | const MX & | x, |
| const std::string & | domain | ||
| ) |
Marks all scalars of x as integer or real (default). The information is passed to the solver as the nlpsol/qpsol option "discrete"; a solver without integer support raises an error at solve().
| x | A decision variable (pure symbol, not an expression) |
| domain | "real" or "integer"; anything else raises an error |
>>> opti = Opti()
>>> x = opti.variable()
>>> opti.set_domain(x, "integer")
>>> opti.minimize((x-1.4)**2)
>>> opti.solver("ipopt", {"print_time": False}, {"print_level": 0, "sb": "yes"})
>>> try:
...   opti.solve()
... except Exception as e:
...   print(str(e).splitlines()[-1])
Discrete variables require a solver with integer support
>>> try:
...   opti.set_domain(x, "binary")
... except Exception as e:
...   print("Unknown domain 'binary'. Known values are 'real', 'integer'." in str(e))
True
>> opti = Opti(); x = opti.variable(); opti.set_domain(x, 'integer');
>> opti.minimize((x-1.4)^2);
>> opti.solver('ipopt', struct('print_time', false), struct('print_level', 0, 'sb', 'yes'));
>> try, opti.solve(); catch e, disp(contains(e.message, 'solver with integer support')); end
1
>> try, opti.set_domain(x, 'binary'); catch e, disp(contains(e.message, 'Unknown')); end
1
julia> opti = ca.Opti();
julia> x = ca.variable(opti);
julia> ca.set_domain(opti, x, "integer")
julia> ca.minimize(opti, (x - 1.4)^2)
julia> ca.solver(opti, "ipopt", Dict("print_time" => false),
                  Dict("print_level" => 0, "sb" => "yes"))
julia> try
           ca.solve(opti)
       catch e
           println(last(split(sprint(showerror, e), "\n")))
       end
Discrete variables require a solver with integer support
julia> try
           ca.set_domain(opti, x, "binary")
       catch e
           msg = "Unknown domain 'binary'. Known values are 'real', 'integer'."
           println(occursin(msg, sprint(showerror, e)))
       end
true
Extra doc: https://github.com/casadi/casadi/wiki/L_27t
Definition at line 189 of file optistack.cpp.
References x().
The guess is used as x0 (and lam_g0 for opti.lam_g or opti.dual(con)) at the next solve(); the default is 0. x may be a variable, a slice of one, or a linear mapping of variables such as 10*x[0]; a nonlinear expression raises an error. Parameters are refused with a hint to use set_value(). The list form takes assignment expressions var==value, as returned by value_variables() or initial(), which makes warm starting a one-liner. Calling this method invalidates value() until the next solve().
| x | Variable (or linear mapping of variables) to initialize |
| v | Numerical value; scalars are broadcast to the shape of x |
>>> opti = Opti()
>>> x = opti.variable(2)
>>> p = opti.parameter()
>>> opti.set_initial(x, 1)
>>> opti.set_initial(10*x[0], 2)
>>> print(opti.initial())
[MX(([0.2, 1]==opti..._x_1))]
>>> try:
...   opti.set_initial(p, 1)
... except Exception as e:
...   print(str(e).splitlines()[-1])
You cannot set an initial value for a parameter. Did you mean 'set_value'?
>>> try:
...   opti.set_initial(x[0]*x[1], 1)
... except Exception as e:
...   print("Use symbols or simple mappings of symbols" in str(e))
True
>> opti = Opti(); x = opti.variable(2); p = opti.parameter();
>> opti.set_initial(x, 1); opti.set_initial(10*x(1), 2);
>> ini = opti.initial(); disp(ini{1})
([0.2, 1]==opti..._x_1)
>> try, opti.set_initial(p, 1); catch e, disp(contains(e.message, 'mean ''set_value''')); end
1
>> try, opti.set_initial(x(1)*x(2), 1); catch e, disp(contains(e.message, 'simple')); end
1
julia> opti = ca.Opti();
julia> x = ca.variable(opti, 2);
julia> p = ca.parameter(opti);
julia> ca.set_initial(opti, x, 1)
julia> ca.set_initial(opti, 10*x[1], 2)
julia> print(ca.initial(opti))
MX[([0.2, 1]==opti..._x_1)]
julia> try
           ca.set_initial(opti, p, 1)
       catch e
           println(last(split(sprint(showerror, e), "\n")))
       end
You cannot set an initial value for a parameter. Did you mean 'set_value'?
julia> try
           ca.set_initial(opti, x[1]*x[2], 1)
       catch e
           msg = "Use symbols or simple mappings of symbols"
           println(occursin(msg, sprint(showerror, e)))
       end
true
Warm start from a previous solution:
>>> opti = Opti()
>>> x = opti.variable()
>>> y = opti.variable()
>>> opti.minimize((y-x**2)**2)
>>> opti.subject_to(x**2+y**2==1)
>>> opti.subject_to(x+y>=1)
>>> opti.solver("ipopt", {"print_time": False}, {"print_level": 0, "sb": "yes"})
>>> sol = opti.solve()
>>> opti.set_initial(sol.value_variables())
>>> opti.set_initial(opti.lam_g, sol.value(opti.lam_g))
>>> opti.solve().stats()["iter_count"] < sol.stats()["iter_count"]
True
>> opti = Opti(); x = opti.variable(); y = opti.variable();
>> opti.minimize((y-x^2)^2); opti.subject_to(x^2+y^2==1); opti.subject_to(x+y>=1);
>> opti.solver('ipopt', struct('print_time', false), struct('print_level', 0, 'sb', 'yes'));
>> sol = opti.solve();
>> opti.set_initial(sol.value_variables());
>> opti.set_initial(opti.lam_g, sol.value(opti.lam_g));
>> sol2 = opti.solve(); s1 = sol.stats(); s2 = sol2.stats();
>> s2.iter_count < s1.iter_count
1
julia> opti = ca.Opti();
julia> x = ca.variable(opti);
julia> y = ca.variable(opti);
julia> ca.minimize(opti, (y - x^2)^2)
julia> ca.subject_to(opti, x^2 + y^2 == 1)
julia> ca.subject_to(opti, x + y >= 1)
julia> ca.solver(opti, "ipopt", Dict("print_time" => false),
                  Dict("print_level" => 0, "sb" => "yes"))
julia> sol = ca.solve(opti);
julia> opti.set_initial(ca.value_variables(sol))
julia> ca.set_initial(opti, ca.lam_g(opti), ca.value(sol, ca.lam_g(opti)))
julia> ca.stats(ca.solve(opti))["iter_count"] < ca.stats(sol)["iter_count"]
true
Extra doc: https://github.com/casadi/casadi/wiki/L_2mt
Definition at line 165 of file optistack.cpp.
References x().
| void casadi::Opti::set_initial | ( | const std::vector< MX > & | assignments | ) |
The guess is used as x0 (and lam_g0 for opti.lam_g or opti.dual(con)) at the next solve(); the default is 0. x may be a variable, a slice of one, or a linear mapping of variables such as 10*x[0]; a nonlinear expression raises an error. Parameters are refused with a hint to use set_value(). The list form takes assignment expressions var==value, as returned by value_variables() or initial(), which makes warm starting a one-liner. Calling this method invalidates value() until the next solve().
| x | Variable (or linear mapping of variables) to initialize |
| v | Numerical value; scalars are broadcast to the shape of x |
>>> opti = Opti()
>>> x = opti.variable(2)
>>> p = opti.parameter()
>>> opti.set_initial(x, 1)
>>> opti.set_initial(10*x[0], 2)
>>> print(opti.initial())
[MX(([0.2, 1]==opti..._x_1))]
>>> try:
...   opti.set_initial(p, 1)
... except Exception as e:
...   print(str(e).splitlines()[-1])
You cannot set an initial value for a parameter. Did you mean 'set_value'?
>>> try:
...   opti.set_initial(x[0]*x[1], 1)
... except Exception as e:
...   print("Use symbols or simple mappings of symbols" in str(e))
True
>> opti = Opti(); x = opti.variable(2); p = opti.parameter();
>> opti.set_initial(x, 1); opti.set_initial(10*x(1), 2);
>> ini = opti.initial(); disp(ini{1})
([0.2, 1]==opti..._x_1)
>> try, opti.set_initial(p, 1); catch e, disp(contains(e.message, 'mean ''set_value''')); end
1
>> try, opti.set_initial(x(1)*x(2), 1); catch e, disp(contains(e.message, 'simple')); end
1
julia> opti = ca.Opti();
julia> x = ca.variable(opti, 2);
julia> p = ca.parameter(opti);
julia> ca.set_initial(opti, x, 1)
julia> ca.set_initial(opti, 10*x[1], 2)
julia> print(ca.initial(opti))
MX[([0.2, 1]==opti..._x_1)]
julia> try
           ca.set_initial(opti, p, 1)
       catch e
           println(last(split(sprint(showerror, e), "\n")))
       end
You cannot set an initial value for a parameter. Did you mean 'set_value'?
julia> try
           ca.set_initial(opti, x[1]*x[2], 1)
       catch e
           msg = "Use symbols or simple mappings of symbols"
           println(occursin(msg, sprint(showerror, e)))
       end
true
Warm start from a previous solution:
>>> opti = Opti()
>>> x = opti.variable()
>>> y = opti.variable()
>>> opti.minimize((y-x**2)**2)
>>> opti.subject_to(x**2+y**2==1)
>>> opti.subject_to(x+y>=1)
>>> opti.solver("ipopt", {"print_time": False}, {"print_level": 0, "sb": "yes"})
>>> sol = opti.solve()
>>> opti.set_initial(sol.value_variables())
>>> opti.set_initial(opti.lam_g, sol.value(opti.lam_g))
>>> opti.solve().stats()["iter_count"] < sol.stats()["iter_count"]
True
>> opti = Opti(); x = opti.variable(); y = opti.variable();
>> opti.minimize((y-x^2)^2); opti.subject_to(x^2+y^2==1); opti.subject_to(x+y>=1);
>> opti.solver('ipopt', struct('print_time', false), struct('print_level', 0, 'sb', 'yes'));
>> sol = opti.solve();
>> opti.set_initial(sol.value_variables());
>> opti.set_initial(opti.lam_g, sol.value(opti.lam_g));
>> sol2 = opti.solve(); s1 = sol.stats(); s2 = sol2.stats();
>> s2.iter_count < s1.iter_count
1
julia> opti = ca.Opti();
julia> x = ca.variable(opti);
julia> y = ca.variable(opti);
julia> ca.minimize(opti, (y - x^2)^2)
julia> ca.subject_to(opti, x^2 + y^2 == 1)
julia> ca.subject_to(opti, x + y >= 1)
julia> ca.solver(opti, "ipopt", Dict("print_time" => false),
                  Dict("print_level" => 0, "sb" => "yes"))
julia> sol = ca.solve(opti);
julia> opti.set_initial(ca.value_variables(sol))
julia> ca.set_initial(opti, ca.lam_g(opti), ca.value(sol, ca.lam_g(opti)))
julia> ca.stats(ca.solve(opti))["iter_count"] < ca.stats(sol)["iter_count"]
true
Extra doc: https://github.com/casadi/casadi/wiki/L_2mt
Definition at line 172 of file optistack.cpp.
The solver works with (x-offset)/scale instead of x; all user-facing values (value(), initial guesses, duals) stay in the original units. Useful when variables differ by orders of magnitude.
| x | Decision variable or linear mapping of variables |
| scale | Scalar or matrix of the shape of x (default 1) |
| offset | Scalar or matrix of the shape of x (default 0) |
>>> opti = Opti()
>>> T = opti.variable()
>>> opti.set_linear_scale(T, 20, 273.15)
>>> opti.minimize((T-300)**2)
>>> opti.solver("ipopt", {"print_time": False}, {"print_level": 0, "sb": "yes"})
>>> sol = opti.solve()
>>> sol.value(T), opti.x_linear_scale, opti.x_linear_scale_offset
(300.0, DM(20), DM(273.15))
>>> opti.debug.arg()["x0"]
DM(-13.6575)
>> opti = Opti(); T = opti.variable();
>> opti.set_linear_scale(T, 20, 273.15); opti.minimize((T-300)^2);
>> opti.solver('ipopt', struct('print_time', false), struct('print_level', 0, 'sb', 'yes'));
>> sol = opti.solve();
>> sol.value(T), opti.x_linear_scale, opti.x_linear_scale_offset
300
20
273.15
>> a = opti.debug.arg(); disp(a.x0)
-13.6575
julia> opti = ca.Opti();
julia> T = ca.variable(opti);
julia> ca.set_linear_scale(opti, T, 20, 273.15)
julia> ca.minimize(opti, (T - 300)^2)
julia> ca.solver(opti, "ipopt", Dict("print_time" => false),
                  Dict("print_level" => 0, "sb" => "yes"))
julia> sol = ca.solve(opti);
julia> ca.value(sol, T)
300.0
julia> ca.x_linear_scale(opti), ca.x_linear_scale_offset(opti)
(20, 273.15)
Extra doc: https://github.com/casadi/casadi/wiki/L_2bs
Definition at line 197 of file optistack.cpp.
References x().
Every parameter that appears in the problem must have a value before solve(); the value stays until changed, so re-solving with new data only needs set_value() and solve(). x may be a parameter, a slice, or a linear mapping of parameters. Decision variables are refused with a hint to use set_initial(). The list form accepts assignment expressions par==value, as returned by value_parameters(). Calling this method invalidates value() of variables until the next solve().
| x | Parameter (or linear mapping of parameters) |
| v | Numerical value; scalars are broadcast |
>>> opti = Opti()
>>> x = opti.variable()
>>> p = opti.parameter(2)
>>> opti.set_value(p, [1, 2])
>>> opti.set_value(p[1], 5)
>>> opti.value(p)
array([1., 5.])
>>> try:
...   opti.set_value(x, 1)
... except Exception as e:
...   print(str(e).splitlines()[-1])
You cannot set a value for a variable. Did you mean 'set_initial'?
>>> opti.set_value([p==7])
>>> opti.value(p)
array([7., 7.])
>> opti = Opti(); x = opti.variable(); p = opti.parameter(2);
>> opti.set_value(p, [1; 2]); opti.set_value(p(2), 5); disp(opti.value(p)')
1 5
>> try, opti.set_value(x, 1); catch e, disp(contains(e.message, 'mean ''set_initial''')); end
1
>> opti.set_value({p==7}); disp(opti.value(p)')
7 7
julia> opti = ca.Opti();
julia> x = ca.variable(opti);
julia> p = ca.parameter(opti, 2);
julia> ca.set_value(opti, p, [1, 2])
julia> ca.set_value(opti, p[2], 5)
julia> ca.value(opti, p)
2-element Vector{Float64}:
 1.0
 5.0
julia> try
           ca.set_value(opti, x, 1)
       catch e
           println(last(split(sprint(showerror, e), "\n")))
       end
You cannot set a value for a variable. Did you mean 'set_initial'?
julia> ca.set_value(opti, [p == 7])
julia> ca.value(opti, p)
2-element Vector{Float64}:
 7.0
 7.0
Extra doc: https://github.com/casadi/casadi/wiki/L_1d
Definition at line 181 of file optistack.cpp.
References x().
| void casadi::Opti::set_value | ( | const std::vector< MX > & | assignments | ) |
Every parameter that appears in the problem must have a value before solve(); the value stays until changed, so re-solving with new data only needs set_value() and solve(). x may be a parameter, a slice, or a linear mapping of parameters. Decision variables are refused with a hint to use set_initial(). The list form accepts assignment expressions par==value, as returned by value_parameters(). Calling this method invalidates value() of variables until the next solve().
| x | Parameter (or linear mapping of parameters) |
| v | Numerical value; scalars are broadcast |
>>> opti = Opti()
>>> x = opti.variable()
>>> p = opti.parameter(2)
>>> opti.set_value(p, [1, 2])
>>> opti.set_value(p[1], 5)
>>> opti.value(p)
array([1., 5.])
>>> try:
...   opti.set_value(x, 1)
... except Exception as e:
...   print(str(e).splitlines()[-1])
You cannot set a value for a variable. Did you mean 'set_initial'?
>>> opti.set_value([p==7])
>>> opti.value(p)
array([7., 7.])
>> opti = Opti(); x = opti.variable(); p = opti.parameter(2);
>> opti.set_value(p, [1; 2]); opti.set_value(p(2), 5); disp(opti.value(p)')
1 5
>> try, opti.set_value(x, 1); catch e, disp(contains(e.message, 'mean ''set_initial''')); end
1
>> opti.set_value({p==7}); disp(opti.value(p)')
7 7
julia> opti = ca.Opti();
julia> x = ca.variable(opti);
julia> p = ca.parameter(opti, 2);
julia> ca.set_value(opti, p, [1, 2])
julia> ca.set_value(opti, p[2], 5)
julia> ca.value(opti, p)
2-element Vector{Float64}:
 1.0
 5.0
julia> try
           ca.set_value(opti, x, 1)
       catch e
           println(last(split(sprint(showerror, e), "\n")))
       end
You cannot set a value for a variable. Did you mean 'set_initial'?
julia> ca.set_value(opti, [p == 7])
julia> ca.value(opti, p)
2-element Vector{Float64}:
 7.0
 7.0
Extra doc: https://github.com/casadi/casadi/wiki/L_1d
Definition at line 205 of file optistack.cpp.
| OptiSol casadi::Opti::solve | ( | ) |
Builds (or reuses) the solver, evaluates the bounds for the current parameter values, runs the solver from the current initial guess and returns an OptiSol snapshot. Raises an error when the solver does not report success (including iteration or time limits, see solve_limited()); the latest iterate then remains available through opti.debug.value() and opti.value(). Calling solve() again without changing anything repeats the same solve from the same initial guess.
>>> opti = Opti()
>>> x = opti.variable()
>>> opti.minimize((x-1)**6)
>>> opti.solver("ipopt", {"print_time": False},
...             {"print_level": 0, "max_iter": 2, "sb": "yes"})
>>> try:
...   opti.solve()
... except Exception as e:
...   print("Solver failed" in str(e), "'Maximum_Iterations_Exceeded'" in str(e))
True True
>>> opti.debug.value(x), opti.return_status()
(0.36, 'Maximum_Iterations_Exceeded')
>>> opti.solver("ipopt", {"print_time": False}, {"print_level": 0, "sb": "yes"})
>>> sol = opti.solve()
>>> sol.value(x), sol.stats()["success"]
(1.0, True)
>> opti = Opti(); x = opti.variable(); opti.minimize((x-1)^6);
>> ipopt = struct('print_level', 0, 'max_iter', 2, 'sb', 'yes');
>> opti.solver('ipopt', struct('print_time', false), ipopt);
>> try, opti.solve(); catch e, disp(contains(e.message, 'Maximum_Iterations_Exceeded')); end
1
>> opti.debug.value(x), opti.return_status()
0.36
Maximum_Iterations_Exceeded
>> opti.solver('ipopt', struct('print_time', false), struct('print_level', 0, 'sb', 'yes'));
>> sol = opti.solve(); s = sol.stats(); disp(sol.value(x)), disp(s.success)
1.0
1
julia> opti = ca.Opti();
julia> x = ca.variable(opti);
julia> ca.minimize(opti, (x - 1)^6)
julia> ca.solver(opti, "ipopt", Dict("print_time" => false),
                  Dict("print_level" => 0, "max_iter" => 2, "sb" => "yes"))
julia> try
           ca.solve(opti)
       catch e
           msg = sprint(showerror, e)
           println(occursin("Solver failed", msg), " ",
                   occursin("'Maximum_Iterations_Exceeded'", msg))
       end
true true
julia> ca.value(ca.debug(opti), x), ca.return_status(opti)
(0.36, "Maximum_Iterations_Exceeded")
julia> ca.solver(opti, "ipopt", Dict("print_time" => false),
                  Dict("print_level" => 0, "sb" => "yes"))
julia> sol = ca.solve(opti);
julia> ca.value(sol, x), ca.stats(sol)["success"]
(1.0, true)
Extra doc: https://github.com/casadi/casadi/wiki/L_2mu
Definition at line 213 of file optistack.cpp.
| OptiSol casadi::Opti::solve_limited | ( | ) |
Same as solve(), but does not raise when the solver stopped because of an iteration or time limit (unified_return_status "SOLVER_RET_LIMITED"); other failures such as infeasibility still raise.
>>> opti = Opti()
>>> x = opti.variable()
>>> opti.minimize((x-1)**6)
>>> opti.solver("ipopt", {"print_time": False},
...             {"print_level": 0, "max_iter": 2, "sb": "yes"})
>>> sol = opti.solve_limited()
>>> sol.stats()["unified_return_status"], sol.value(x)
('SOLVER_RET_LIMITED', 0.36)
>> opti = Opti(); x = opti.variable(); opti.minimize((x-1)^6);
>> ipopt = struct('print_level', 0, 'max_iter', 2, 'sb', 'yes');
>> opti.solver('ipopt', struct('print_time', false), ipopt);
>> sol = opti.solve_limited(); s = sol.stats();
>> s.unified_return_status, sol.value(x)
SOLVER_RET_LIMITED
0.36
julia> opti = ca.Opti();
julia> x = ca.variable(opti);
julia> ca.minimize(opti, (x - 1)^6)
julia> ca.solver(opti, "ipopt", Dict("print_time" => false),
                  Dict("print_level" => 0, "max_iter" => 2, "sb" => "yes"))
julia> sol = ca.solve_limited(opti);
julia> ca.stats(sol)["unified_return_status"], ca.value(sol, x)
("SOLVER_RET_LIMITED", 0.36)
Extra doc: https://github.com/casadi/casadi/wiki/L_1e
Definition at line 221 of file optistack.cpp.
| void casadi::Opti::solver | ( | const std::string & | solver, |
| const Dict & | plugin_options = Dict(), |
||
| const Dict & | solver_options = Dict() |
||
| ) |
Must be called before solve(). The solver is (re)constructed lazily at the next solve() when this method or the problem structure changed.
| solver | Name of an nlpsol plugin ("ipopt", "sqpmethod", "bonmin", ...) or, for a "conic" Opti, of a qpsol plugin ("qrqp", "qpoases", "osqp", ...) |
| plugin_options | Dict passed as-is to nlpsol/qpsol: CasADi-level options such as "print_time", "expand", "detect_simple_bounds", "error_on_fail", "iteration_callback", and plugin options that are registered as CasADi options (e.g. "qpsol" and "print_iteration" of sqpmethod, "print_iter" of qrqp) |
| solver_options | Dict of the back-end's native options; it is nested under the key solver, so {"max_iter": 50} here equals {"ipopt": {"max_iter": 50}} in plugin_options. Opti also sets the nlpsol options "equality" and "discrete" unless given explicitly. |
No stability is guaranteed for option names; they belong to the plugins.
>>> opti = Opti()
>>> x = opti.variable()
>>> opti.minimize((x-2)**2)
>>> try:
...   opti.solve()
... except Exception as e:
...   print("You must call 'solver' on the Opti stack" in str(e))
True
>>> opti.solver("ipopt", {"print_time": False}, {"print_level": 0, "sb": "yes"})
>>> opti.solve().value(x)
2.0
>>> opti.solver("sqpmethod", {"print_time": False, "print_header": False,
...   "print_iteration": False, "print_status": False, "qpsol": "qrqp",
...   "qpsol_options": {"print_iter": False, "print_header": False, "print_info": False}})
>>> opti.solve().value(x)
2.0
>> opti = Opti(); x = opti.variable(); opti.minimize((x-2)^2);
>> try, opti.solve(); catch e, disp(contains(e.message, 'You must call ''solver''')); end
1
>> opti.solver('ipopt', struct('print_time', false), struct('print_level', 0, 'sb', 'yes'));
>> sol = opti.solve(); disp(sol.value(x))
2
>> qp = struct('print_iter', false, 'print_header', false, 'print_info', false);
>> opts = struct('print_time', false, 'print_header', false, 'print_iteration', false);
>> opts.print_status = false; opts.qpsol = 'qrqp'; opts.qpsol_options = qp;
>> opti.solver('sqpmethod', opts); sol = opti.solve(); disp(sol.value(x))
2
julia> opti = ca.Opti();
julia> x = ca.variable(opti);
julia> ca.minimize(opti, (x - 2)^2)
julia> try
           ca.solve(opti)
       catch e
           println(occursin("You must call 'solver' on the Opti stack", sprint(showerror, e)))
       end
true
julia> ca.solver(opti, "ipopt", Dict("print_time" => false),
                  Dict("print_level" => 0, "sb" => "yes"))
julia> ca.value(ca.solve(opti), x)
2.0
julia> qp_opts = Dict("print_iter" => false, "print_header" => false, "print_info" => false);
julia> ca.solver(opti, "sqpmethod", Dict("print_time" => false, "print_header" => false,
           "print_iteration" => false, "print_status" => false, "qpsol" => "qrqp",
           "qpsol_options" => qp_opts))
julia> ca.value(ca.solve(opti), x)
2.0
Extra doc: https://github.com/casadi/casadi/wiki/L_1c
Definition at line 155 of file optistack.cpp.
| Dict casadi::Opti::stats | ( | ) | const |
The dict returned by the nlpsol/qpsol plugin, passed as-is: always "success", "return_status" and "unified_return_status", plus plugin-specific entries such as "iter_count". Raises an error before the first solve(). No stability is guaranteed for the plugin-specific entries.
>>> opti = Opti()
>>> x = opti.variable()
>>> opti.minimize((x-1)**2)
>>> opti.solver("ipopt", {"print_time": False}, {"print_level": 0, "sb": "yes"})
>>> sol = opti.solve()
>>> s = sol.stats()
>>> s["success"], s["return_status"], s["unified_return_status"], s["iter_count"]
(True, 'Solve_Succeeded', 'SOLVER_RET_SUCCESS', 1)
>> opti = Opti(); x = opti.variable(); opti.minimize((x-1)^2);
>> opti.solver('ipopt', struct('print_time', false), struct('print_level', 0, 'sb', 'yes'));
>> sol = opti.solve(); s = sol.stats();
>> s.success, s.return_status, s.unified_return_status, s.iter_count
1
Solve_Succeeded
SOLVER_RET_SUCCESS
1
julia> opti = ca.Opti();
julia> x = ca.variable(opti);
julia> ca.minimize(opti, (x - 1)^2)
julia> ca.solver(opti, "ipopt", Dict("print_time" => false),
                  Dict("print_level" => 0, "sb" => "yes"))
julia> sol = ca.solve(opti);
julia> s = ca.stats(sol);
julia> s["success"], s["return_status"], s["unified_return_status"], s["iter_count"]
(true, "Solve_Succeeded", "SOLVER_RET_SUCCESS", 1)
Extra doc: https://github.com/casadi/casadi/wiki/L_1f
Definition at line 262 of file optistack.cpp.
Referenced by casadi::OptiSol::stats().
| void casadi::Opti::subject_to | ( | ) |
Removes every constraint added so far, including their dual variables, so the problem can be restated (typical when the constraint set changes between solves). The objective, variables, parameters, values and initial guesses are kept.
>>> opti = Opti()
>>> x = opti.variable()
>>> con = x >= 1
>>> opti.subject_to(con)
>>> opti.minimize(x**2)
>>> opti.ng
1
>>> opti.subject_to()
>>> opti.ng
0
>>> opti.solver("ipopt", {"print_time": False}, {"print_level": 0, "sb": "yes"})
>>> sol = opti.solve()
>>> try:
...   sol.value(opti.dual(con))
... except Exception as e:
...   print(str(e).splitlines()[-2])
This expression has a dual for a constraint that is not given to Opti:
>> opti = Opti(); x = opti.variable(); con = x >= 1;
>> opti.subject_to(con); opti.minimize(x^2); disp(opti.ng)
1
>> opti.subject_to(); disp(opti.ng)
0
>> opti.solver('ipopt', struct('print_time', false), struct('print_level', 0, 'sb', 'yes'));
>> sol = opti.solve();
>> try, sol.value(opti.dual(con)); catch e, disp(contains(e.message, 'not given')); end
1
julia> opti = ca.Opti();
julia> x = ca.variable(opti);
julia> con = x >= 1;
julia> ca.subject_to(opti, con)
julia> ca.minimize(opti, x^2)
julia> ca.ng(opti)
1
julia> ca.subject_to(opti)
julia> ca.ng(opti)
0
julia> ca.solver(opti, "ipopt", Dict("print_time" => false),
                  Dict("print_level" => 0, "sb" => "yes"))
julia> sol = ca.solve(opti);
julia> try
           ca.value(sol, ca.dual(opti, con))
       catch e
           println(split(sprint(showerror, e), "\n")[end-1])
       end
This expression has a dual for a constraint that is not given to Opti:
Extra doc: https://github.com/casadi/casadi/wiki/L_2ms
Definition at line 146 of file optistack.cpp.
Referenced by subject_to().
g is a comparison expression built with ==, <=, >= (< and > behave as <= and >=). Vector expressions give one constraint per element; both sides may be vectors of the same shape or a scalar that is broadcast. Each call appends to the constraint set.
Recognized forms and how they reach the solver:
Errors: a constant comparison, an empty or fully sparse expression, a symbol not declared by this instance, and dual variables all raise an error immediately. A square matrix comparison A >= B is interpreted as a semidefinite constraint, which "nlp" does not support: vectorize the matrix with vec(A) for an elementwise constraint. An expression without comparison operator is accepted but rejected at solve().
| g | Constraint expression, or a list of them (each added in turn) |
| linear_scale | Scalar or same-shape matrix; the solver sees g divided by it |
| options | Dict with optional entries "meta" (dict stored in the user_dict of the constraint) and "stacktrace"; any other key raises an error |
>>> opti = Opti()
>>> x = opti.variable(3)
>>> y = opti.variable()
>>> p = opti.parameter()
>>> opti.subject_to(x >= 0)
>>> opti.subject_to(x[0] + x[1] == p)
>>> opti.subject_to(-1 <= (y <= 1))
>>> opti.subject_to([y >= x[2], y*x[0] >= 1])
>>> opti.ng
7
>>> print(opti.lbg, opti.ubg)
vertcat(zeros(3x1), opti..._p_1, -1, -inf, 1) vertcat(inf(3x1), opti..._p_1, 1, 0, inf)
>>> try:
...   opti.subject_to(0 <= y <= 1)
... except Exception as e:
...   print("Can only determine truth value of a numeric MX" in str(e))
True
>>> try:
...   opti.subject_to(MX(2) <= 3)
... except Exception as e:
...   print(str(e).splitlines()[-1])
You passed a constant to `subject_to`. You need a symbol to form a constraint.
>>> try:
...   opti.subject_to(MX.sym("w") <= 3)
... except Exception as e:
...   print("MX symbol 'w' of shape 1x1, declared outside of Opti" in str(e))
True
>> opti = Opti(); x = opti.variable(3); y = opti.variable(); p = opti.parameter();
>> opti.subject_to(x >= 0);
>> opti.subject_to(x(1) + x(2) == p);
>> opti.subject_to(-1 <= y <= 1);
>> opti.subject_to({y >= x(3), y*x(1) >= 1});
>> opti.ng
7
>> opti.lbg, opti.ubg
vertcat(zeros(3x1), opti..._p_1, -1, -inf, 1)
vertcat(inf(3x1), opti..._p_1, 1, 0, inf)
>> try, opti.subject_to(MX(2) <= 3); catch e, disp(contains(e.message, 'a constant')); end
1
>> w = MX.sym('w');
>> try, opti.subject_to(w <= 3); catch e, disp(contains(e.message, 'outside of Opti')); end
1
julia> opti = ca.Opti();
julia> x = ca.variable(opti, 3);
julia> y = ca.variable(opti);
julia> p = ca.parameter(opti);
julia> ca.subject_to(opti, x >= 0)
julia> ca.subject_to(opti, x[1] + x[2] == p)
julia> ca.subject_to(opti, -1 <= (y <= 1))
julia> ca.subject_to(opti, [y >= x[3], y*x[1] >= 1])
julia> ca.ng(opti)
7
julia> print(ca.lbg(opti), " ", ca.ubg(opti))
vertcat(zeros(3x1), opti..._p_1, -1, -inf, 1) vertcat(inf(3x1), opti..._p_1, 1, 0, inf)
julia> try
           ca.subject_to(opti, 0 <= y <= 1)
       catch e
           println(typeof(e))
       end
TypeError
julia> try
           ca.subject_to(opti, ca.MX(2) <= 3)
       catch e
           println(last(split(sprint(showerror, e), "\n")))
       end
You passed a constant to `subject_to`. You need a symbol to form a constraint.
julia> try
           ca.subject_to(opti, ca.MX.sym("w") <= 3)
       catch e
           msg = "MX symbol 'w' of shape 1x1, declared outside of Opti"
           println(occursin(msg, sprint(showerror, e)))
       end
true
Elementwise constraints on matrices need vec(); options attach metadata:
>>> opti = Opti()
>>> A = opti.variable(2, 2)
>>> opti.subject_to(A >= 0)
>>> opti.minimize(sumsqr(A))
>>> opti.solver("ipopt", {"print_time": False}, {"print_level": 0, "sb": "yes"})
>>> try:
...   opti.solve()
... except Exception as e:
...   print("Psd constraints not implemented yet" in str(e))
True
>>> opti.subject_to()
>>> con = vec(A) >= 0
>>> opti.subject_to(con, {"meta": {"label": "nonneg"}})
>>> opti.ng, opti.user_dict(con)["label"]
(4, 'nonneg')
>> opti = Opti(); A = opti.variable(2, 2);
>> opti.subject_to(A >= 0); opti.minimize(sumsqr(A));
>> opti.solver('ipopt', struct('print_time', false), struct('print_level', 0, 'sb', 'yes'));
>> try, opti.solve(); catch e, disp(contains(e.message, 'Psd constraints')); end
1
>> opti.subject_to(); con = vec(A) >= 0;
>> opti.subject_to(con, struct('meta', struct('label', 'nonneg')));
>> d = opti.user_dict(con); fprintf('%d %s\n', opti.ng, d.label)
4 nonneg
julia> opti = ca.Opti();
julia> A = ca.variable(opti, 2, 2);
julia> ca.subject_to(opti, A >= 0)
julia> ca.minimize(opti, ca.sumsqr(A))
julia> ca.solver(opti, "ipopt", Dict("print_time" => false),
                  Dict("print_level" => 0, "sb" => "yes"))
julia> try
           ca.solve(opti)
       catch e
           println(occursin("Psd constraints not implemented yet", sprint(showerror, e)))
       end
true
julia> ca.subject_to(opti)
julia> con = vec(A) >= 0;
julia> ca.subject_to(opti, con, Dict("meta" => Dict("label" => "nonneg")))
julia> ca.ng(opti), ca.user_dict(opti, con)["label"]
(4, "nonneg")
Extra doc: https://github.com/casadi/casadi/wiki/L_1b
Definition at line 122 of file optistack.cpp.
References g().
| void casadi::Opti::subject_to | ( | const MX & | g, |
| const DM & | linear_scale, | ||
| const Dict & | options = Dict() |
||
| ) |
g is a comparison expression built with ==, <=, >= (< and > behave as <= and >=). Vector expressions give one constraint per element; both sides may be vectors of the same shape or a scalar that is broadcast. Each call appends to the constraint set.
Recognized forms and how they reach the solver:
Errors: a constant comparison, an empty or fully sparse expression, a symbol not declared by this instance, and dual variables all raise an error immediately. A square matrix comparison A >= B is interpreted as a semidefinite constraint, which "nlp" does not support: vectorize the matrix with vec(A) for an elementwise constraint. An expression without comparison operator is accepted but rejected at solve().
| g | Constraint expression, or a list of them (each added in turn) |
| linear_scale | Scalar or same-shape matrix; the solver sees g divided by it |
| options | Dict with optional entries "meta" (dict stored in the user_dict of the constraint) and "stacktrace"; any other key raises an error |
>>> opti = Opti()
>>> x = opti.variable(3)
>>> y = opti.variable()
>>> p = opti.parameter()
>>> opti.subject_to(x >= 0)
>>> opti.subject_to(x[0] + x[1] == p)
>>> opti.subject_to(-1 <= (y <= 1))
>>> opti.subject_to([y >= x[2], y*x[0] >= 1])
>>> opti.ng
7
>>> print(opti.lbg, opti.ubg)
vertcat(zeros(3x1), opti..._p_1, -1, -inf, 1) vertcat(inf(3x1), opti..._p_1, 1, 0, inf)
>>> try:
...   opti.subject_to(0 <= y <= 1)
... except Exception as e:
...   print("Can only determine truth value of a numeric MX" in str(e))
True
>>> try:
...   opti.subject_to(MX(2) <= 3)
... except Exception as e:
...   print(str(e).splitlines()[-1])
You passed a constant to `subject_to`. You need a symbol to form a constraint.
>>> try:
...   opti.subject_to(MX.sym("w") <= 3)
... except Exception as e:
...   print("MX symbol 'w' of shape 1x1, declared outside of Opti" in str(e))
True
>> opti = Opti(); x = opti.variable(3); y = opti.variable(); p = opti.parameter();
>> opti.subject_to(x >= 0);
>> opti.subject_to(x(1) + x(2) == p);
>> opti.subject_to(-1 <= y <= 1);
>> opti.subject_to({y >= x(3), y*x(1) >= 1});
>> opti.ng
7
>> opti.lbg, opti.ubg
vertcat(zeros(3x1), opti..._p_1, -1, -inf, 1)
vertcat(inf(3x1), opti..._p_1, 1, 0, inf)
>> try, opti.subject_to(MX(2) <= 3); catch e, disp(contains(e.message, 'a constant')); end
1
>> w = MX.sym('w');
>> try, opti.subject_to(w <= 3); catch e, disp(contains(e.message, 'outside of Opti')); end
1
julia> opti = ca.Opti();
julia> x = ca.variable(opti, 3);
julia> y = ca.variable(opti);
julia> p = ca.parameter(opti);
julia> ca.subject_to(opti, x >= 0)
julia> ca.subject_to(opti, x[1] + x[2] == p)
julia> ca.subject_to(opti, -1 <= (y <= 1))
julia> ca.subject_to(opti, [y >= x[3], y*x[1] >= 1])
julia> ca.ng(opti)
7
julia> print(ca.lbg(opti), " ", ca.ubg(opti))
vertcat(zeros(3x1), opti..._p_1, -1, -inf, 1) vertcat(inf(3x1), opti..._p_1, 1, 0, inf)
julia> try
           ca.subject_to(opti, 0 <= y <= 1)
       catch e
           println(typeof(e))
       end
TypeError
julia> try
           ca.subject_to(opti, ca.MX(2) <= 3)
       catch e
           println(last(split(sprint(showerror, e), "\n")))
       end
You passed a constant to `subject_to`. You need a symbol to form a constraint.
julia> try
           ca.subject_to(opti, ca.MX.sym("w") <= 3)
       catch e
           msg = "MX symbol 'w' of shape 1x1, declared outside of Opti"
           println(occursin(msg, sprint(showerror, e)))
       end
true
Elementwise constraints on matrices need vec(); options attach metadata:
>>> opti = Opti()
>>> A = opti.variable(2, 2)
>>> opti.subject_to(A >= 0)
>>> opti.minimize(sumsqr(A))
>>> opti.solver("ipopt", {"print_time": False}, {"print_level": 0, "sb": "yes"})
>>> try:
...   opti.solve()
... except Exception as e:
...   print("Psd constraints not implemented yet" in str(e))
True
>>> opti.subject_to()
>>> con = vec(A) >= 0
>>> opti.subject_to(con, {"meta": {"label": "nonneg"}})
>>> opti.ng, opti.user_dict(con)["label"]
(4, 'nonneg')
>> opti = Opti(); A = opti.variable(2, 2);
>> opti.subject_to(A >= 0); opti.minimize(sumsqr(A));
>> opti.solver('ipopt', struct('print_time', false), struct('print_level', 0, 'sb', 'yes'));
>> try, opti.solve(); catch e, disp(contains(e.message, 'Psd constraints')); end
1
>> opti.subject_to(); con = vec(A) >= 0;
>> opti.subject_to(con, struct('meta', struct('label', 'nonneg')));
>> d = opti.user_dict(con); fprintf('%d %s\n', opti.ng, d.label)
4 nonneg
julia> opti = ca.Opti();
julia> A = ca.variable(opti, 2, 2);
julia> ca.subject_to(opti, A >= 0)
julia> ca.minimize(opti, ca.sumsqr(A))
julia> ca.solver(opti, "ipopt", Dict("print_time" => false),
                  Dict("print_level" => 0, "sb" => "yes"))
julia> try
           ca.solve(opti)
       catch e
           println(occursin("Psd constraints not implemented yet", sprint(showerror, e)))
       end
true
julia> ca.subject_to(opti)
julia> con = vec(A) >= 0;
julia> ca.subject_to(opti, con, Dict("meta" => Dict("label" => "nonneg")))
julia> ca.ng(opti), ca.user_dict(opti, con)["label"]
(4, "nonneg")
Extra doc: https://github.com/casadi/casadi/wiki/L_1b
Definition at line 134 of file optistack.cpp.
References g().
g is a comparison expression built with ==, <=, >= (< and > behave as <= and >=). Vector expressions give one constraint per element; both sides may be vectors of the same shape or a scalar that is broadcast. Each call appends to the constraint set.
Recognized forms and how they reach the solver:
Errors: a constant comparison, an empty or fully sparse expression, a symbol not declared by this instance, and dual variables all raise an error immediately. A square matrix comparison A >= B is interpreted as a semidefinite constraint, which "nlp" does not support: vectorize the matrix with vec(A) for an elementwise constraint. An expression without comparison operator is accepted but rejected at solve().
| g | Constraint expression, or a list of them (each added in turn) |
| linear_scale | Scalar or same-shape matrix; the solver sees g divided by it |
| options | Dict with optional entries "meta" (dict stored in the user_dict of the constraint) and "stacktrace"; any other key raises an error |
>>> opti = Opti()
>>> x = opti.variable(3)
>>> y = opti.variable()
>>> p = opti.parameter()
>>> opti.subject_to(x >= 0)
>>> opti.subject_to(x[0] + x[1] == p)
>>> opti.subject_to(-1 <= (y <= 1))
>>> opti.subject_to([y >= x[2], y*x[0] >= 1])
>>> opti.ng
7
>>> print(opti.lbg, opti.ubg)
vertcat(zeros(3x1), opti..._p_1, -1, -inf, 1) vertcat(inf(3x1), opti..._p_1, 1, 0, inf)
>>> try:
...   opti.subject_to(0 <= y <= 1)
... except Exception as e:
...   print("Can only determine truth value of a numeric MX" in str(e))
True
>>> try:
...   opti.subject_to(MX(2) <= 3)
... except Exception as e:
...   print(str(e).splitlines()[-1])
You passed a constant to `subject_to`. You need a symbol to form a constraint.
>>> try:
...   opti.subject_to(MX.sym("w") <= 3)
... except Exception as e:
...   print("MX symbol 'w' of shape 1x1, declared outside of Opti" in str(e))
True
>> opti = Opti(); x = opti.variable(3); y = opti.variable(); p = opti.parameter();
>> opti.subject_to(x >= 0);
>> opti.subject_to(x(1) + x(2) == p);
>> opti.subject_to(-1 <= y <= 1);
>> opti.subject_to({y >= x(3), y*x(1) >= 1});
>> opti.ng
7
>> opti.lbg, opti.ubg
vertcat(zeros(3x1), opti..._p_1, -1, -inf, 1)
vertcat(inf(3x1), opti..._p_1, 1, 0, inf)
>> try, opti.subject_to(MX(2) <= 3); catch e, disp(contains(e.message, 'a constant')); end
1
>> w = MX.sym('w');
>> try, opti.subject_to(w <= 3); catch e, disp(contains(e.message, 'outside of Opti')); end
1
julia> opti = ca.Opti();
julia> x = ca.variable(opti, 3);
julia> y = ca.variable(opti);
julia> p = ca.parameter(opti);
julia> ca.subject_to(opti, x >= 0)
julia> ca.subject_to(opti, x[1] + x[2] == p)
julia> ca.subject_to(opti, -1 <= (y <= 1))
julia> ca.subject_to(opti, [y >= x[3], y*x[1] >= 1])
julia> ca.ng(opti)
7
julia> print(ca.lbg(opti), " ", ca.ubg(opti))
vertcat(zeros(3x1), opti..._p_1, -1, -inf, 1) vertcat(inf(3x1), opti..._p_1, 1, 0, inf)
julia> try
           ca.subject_to(opti, 0 <= y <= 1)
       catch e
           println(typeof(e))
       end
TypeError
julia> try
           ca.subject_to(opti, ca.MX(2) <= 3)
       catch e
           println(last(split(sprint(showerror, e), "\n")))
       end
You passed a constant to `subject_to`. You need a symbol to form a constraint.
julia> try
           ca.subject_to(opti, ca.MX.sym("w") <= 3)
       catch e
           msg = "MX symbol 'w' of shape 1x1, declared outside of Opti"
           println(occursin(msg, sprint(showerror, e)))
       end
true
Elementwise constraints on matrices need vec(); options attach metadata:
>>> opti = Opti()
>>> A = opti.variable(2, 2)
>>> opti.subject_to(A >= 0)
>>> opti.minimize(sumsqr(A))
>>> opti.solver("ipopt", {"print_time": False}, {"print_level": 0, "sb": "yes"})
>>> try:
...   opti.solve()
... except Exception as e:
...   print("Psd constraints not implemented yet" in str(e))
True
>>> opti.subject_to()
>>> con = vec(A) >= 0
>>> opti.subject_to(con, {"meta": {"label": "nonneg"}})
>>> opti.ng, opti.user_dict(con)["label"]
(4, 'nonneg')
>> opti = Opti(); A = opti.variable(2, 2);
>> opti.subject_to(A >= 0); opti.minimize(sumsqr(A));
>> opti.solver('ipopt', struct('print_time', false), struct('print_level', 0, 'sb', 'yes'));
>> try, opti.solve(); catch e, disp(contains(e.message, 'Psd constraints')); end
1
>> opti.subject_to(); con = vec(A) >= 0;
>> opti.subject_to(con, struct('meta', struct('label', 'nonneg')));
>> d = opti.user_dict(con); fprintf('%d %s\n', opti.ng, d.label)
4 nonneg
julia> opti = ca.Opti();
julia> A = ca.variable(opti, 2, 2);
julia> ca.subject_to(opti, A >= 0)
julia> ca.minimize(opti, ca.sumsqr(A))
julia> ca.solver(opti, "ipopt", Dict("print_time" => false),
                  Dict("print_level" => 0, "sb" => "yes"))
julia> try
           ca.solve(opti)
       catch e
           println(occursin("Psd constraints not implemented yet", sprint(showerror, e)))
       end
true
julia> ca.subject_to(opti)
julia> con = vec(A) >= 0;
julia> ca.subject_to(opti, con, Dict("meta" => Dict("label" => "nonneg")))
julia> ca.ng(opti), ca.user_dict(opti, con)["label"]
(4, "nonneg")
Extra doc: https://github.com/casadi/casadi/wiki/L_1b
Definition at line 130 of file optistack.cpp.
References g(), and subject_to().
| void casadi::Opti::subject_to | ( | const std::vector< MX > & | g, |
| const DM & | linear_scale, | ||
| const Dict & | options = Dict() |
||
| ) |
g is a comparison expression built with ==, <=, >= (< and > behave as <= and >=). Vector expressions give one constraint per element; both sides may be vectors of the same shape or a scalar that is broadcast. Each call appends to the constraint set.
Recognized forms and how they reach the solver:
Errors: a constant comparison, an empty or fully sparse expression, a symbol not declared by this instance, and dual variables all raise an error immediately. A square matrix comparison A >= B is interpreted as a semidefinite constraint, which "nlp" does not support: vectorize the matrix with vec(A) for an elementwise constraint. An expression without comparison operator is accepted but rejected at solve().
| g | Constraint expression, or a list of them (each added in turn) |
| linear_scale | Scalar or same-shape matrix; the solver sees g divided by it |
| options | Dict with optional entries "meta" (dict stored in the user_dict of the constraint) and "stacktrace"; any other key raises an error |
>>> opti = Opti()
>>> x = opti.variable(3)
>>> y = opti.variable()
>>> p = opti.parameter()
>>> opti.subject_to(x >= 0)
>>> opti.subject_to(x[0] + x[1] == p)
>>> opti.subject_to(-1 <= (y <= 1))
>>> opti.subject_to([y >= x[2], y*x[0] >= 1])
>>> opti.ng
7
>>> print(opti.lbg, opti.ubg)
vertcat(zeros(3x1), opti..._p_1, -1, -inf, 1) vertcat(inf(3x1), opti..._p_1, 1, 0, inf)
>>> try:
...   opti.subject_to(0 <= y <= 1)
... except Exception as e:
...   print("Can only determine truth value of a numeric MX" in str(e))
True
>>> try:
...   opti.subject_to(MX(2) <= 3)
... except Exception as e:
...   print(str(e).splitlines()[-1])
You passed a constant to `subject_to`. You need a symbol to form a constraint.
>>> try:
...   opti.subject_to(MX.sym("w") <= 3)
... except Exception as e:
...   print("MX symbol 'w' of shape 1x1, declared outside of Opti" in str(e))
True
>> opti = Opti(); x = opti.variable(3); y = opti.variable(); p = opti.parameter();
>> opti.subject_to(x >= 0);
>> opti.subject_to(x(1) + x(2) == p);
>> opti.subject_to(-1 <= y <= 1);
>> opti.subject_to({y >= x(3), y*x(1) >= 1});
>> opti.ng
7
>> opti.lbg, opti.ubg
vertcat(zeros(3x1), opti..._p_1, -1, -inf, 1)
vertcat(inf(3x1), opti..._p_1, 1, 0, inf)
>> try, opti.subject_to(MX(2) <= 3); catch e, disp(contains(e.message, 'a constant')); end
1
>> w = MX.sym('w');
>> try, opti.subject_to(w <= 3); catch e, disp(contains(e.message, 'outside of Opti')); end
1
julia> opti = ca.Opti();
julia> x = ca.variable(opti, 3);
julia> y = ca.variable(opti);
julia> p = ca.parameter(opti);
julia> ca.subject_to(opti, x >= 0)
julia> ca.subject_to(opti, x[1] + x[2] == p)
julia> ca.subject_to(opti, -1 <= (y <= 1))
julia> ca.subject_to(opti, [y >= x[3], y*x[1] >= 1])
julia> ca.ng(opti)
7
julia> print(ca.lbg(opti), " ", ca.ubg(opti))
vertcat(zeros(3x1), opti..._p_1, -1, -inf, 1) vertcat(inf(3x1), opti..._p_1, 1, 0, inf)
julia> try
           ca.subject_to(opti, 0 <= y <= 1)
       catch e
           println(typeof(e))
       end
TypeError
julia> try
           ca.subject_to(opti, ca.MX(2) <= 3)
       catch e
           println(last(split(sprint(showerror, e), "\n")))
       end
You passed a constant to `subject_to`. You need a symbol to form a constraint.
julia> try
           ca.subject_to(opti, ca.MX.sym("w") <= 3)
       catch e
           msg = "MX symbol 'w' of shape 1x1, declared outside of Opti"
           println(occursin(msg, sprint(showerror, e)))
       end
true
Elementwise constraints on matrices need vec(); options attach metadata:
>>> opti = Opti()
>>> A = opti.variable(2, 2)
>>> opti.subject_to(A >= 0)
>>> opti.minimize(sumsqr(A))
>>> opti.solver("ipopt", {"print_time": False}, {"print_level": 0, "sb": "yes"})
>>> try:
...   opti.solve()
... except Exception as e:
...   print("Psd constraints not implemented yet" in str(e))
True
>>> opti.subject_to()
>>> con = vec(A) >= 0
>>> opti.subject_to(con, {"meta": {"label": "nonneg"}})
>>> opti.ng, opti.user_dict(con)["label"]
(4, 'nonneg')
>> opti = Opti(); A = opti.variable(2, 2);
>> opti.subject_to(A >= 0); opti.minimize(sumsqr(A));
>> opti.solver('ipopt', struct('print_time', false), struct('print_level', 0, 'sb', 'yes'));
>> try, opti.solve(); catch e, disp(contains(e.message, 'Psd constraints')); end
1
>> opti.subject_to(); con = vec(A) >= 0;
>> opti.subject_to(con, struct('meta', struct('label', 'nonneg')));
>> d = opti.user_dict(con); fprintf('%d %s\n', opti.ng, d.label)
4 nonneg
julia> opti = ca.Opti();
julia> A = ca.variable(opti, 2, 2);
julia> ca.subject_to(opti, A >= 0)
julia> ca.minimize(opti, ca.sumsqr(A))
julia> ca.solver(opti, "ipopt", Dict("print_time" => false),
                  Dict("print_level" => 0, "sb" => "yes"))
julia> try
           ca.solve(opti)
       catch e
           println(occursin("Psd constraints not implemented yet", sprint(showerror, e)))
       end
true
julia> ca.subject_to(opti)
julia> con = vec(A) >= 0;
julia> ca.subject_to(opti, con, Dict("meta" => Dict("label" => "nonneg")))
julia> ca.ng(opti), ca.user_dict(opti, con)["label"]
(4, "nonneg")
Extra doc: https://github.com/casadi/casadi/wiki/L_1b
Definition at line 142 of file optistack.cpp.
References g(), and subject_to().
|
inherited |
Definition at line 105 of file generic_shared_impl.hpp.
| Function casadi::Opti::to_function | ( | const std::string & | name, |
| const std::map< std::string, MX > & | dict, | ||
| const std::vector< std::string > & | name_in, | ||
| const std::vector< std::string > & | name_out, | ||
| const Dict & | opts = Dict() |
||
| ) |
Definition at line 441 of file optistack.cpp.
References casadi::find(), and to_function().
| Function casadi::Opti::to_function | ( | const std::string & | name, |
| const std::vector< MX > & | args, | ||
| const std::vector< MX > & | res, | ||
| const Dict & | opts = Dict() |
||
| ) |
Packs bounds evaluation, the solver call and the evaluation of res into one Function, which is much cheaper to call repeatedly than set_value/solve/value. Inputs corresponding to parameters supply their values; inputs corresponding to variables or dual variables supply the initial guess; anything not listed keeps the value stored in the Opti at the time of the call. Outputs are evaluated at the solution.
A solver failure does not raise by default: the last iterate is returned and the Function's stats() report success False. Pass "error_on_fail": True in the plugin_options of solver() to raise instead. Function options in opts are applied to the result; the entry "helper_options" is applied to the internal evaluation function.
| name | Name of the resulting Function |
| args | List of parameters, decision variables and dual variables (or vertcat of them); each must be purely symbolic and independent, else an error is raised |
| res | List of expressions evaluated at the solution |
| name_in | Optional input names (same length as args) |
| name_out | Optional output names (same length as res) |
| opts | Function options |
>>> opti = Opti()
>>> x = opti.variable()
>>> y = opti.variable()
>>> p = opti.parameter()
>>> opti.minimize((x-p)**2 + (y-x)**2)
>>> opti.subject_to(x >= 0)
>>> opti.solver("ipopt", {"print_time": False}, {"print_level": 0, "sb": "yes"})
>>> F = opti.to_function("F", [p, x], [vertcat(x, y), opti.lam_g],
...                      ["p", "x0"], ["xy", "lam"])
>>> F
Function(F:(p,x0)->(xy[2],lam) MXFunction)
>>> r = F(p=2, x0=1)
>>> r["xy"], r["lam"]
(DM([2, 2]), DM(0.0000))
>>> F.stats()["success"]
True
>>> F = opti.to_function("F", {"p": p, "x": x}, ["p"], ["x"])
>>> F(3)
DM(3)
>>> try:
...   opti.to_function("F", [p+1], [x])
... except Exception as e:
...   print(str(e).splitlines()[-1])
Argument 0 is not purely symbolic.
>> opti = Opti(); x = opti.variable(); y = opti.variable(); p = opti.parameter();
>> opti.minimize((x-p)^2 + (y-x)^2); opti.subject_to(x >= 0);
>> opti.solver('ipopt', struct('print_time', false), struct('print_level', 0, 'sb', 'yes'));
>> F = opti.to_function('F', {p, x}, {vertcat(x, y), opti.lam_g}, {'p', 'x0'}, {'xy', 'lam'});
>> F
F:(p,x0)->(xy[2],lam) MXFunction
>> r = F('p', 2, 'x0', 1); disp(r.xy), disp(r.lam)
[2, 2]
0.0000
>> s = F.stats(); disp(s.success)
1
>> F = opti.to_function('F', struct('p', p, 'x', x), {'p'}, {'x'}); disp(F(3))
3
>> try, opti.to_function('F', {p+1}, {x}); catch e, disp(contains(e.message, 'symbolic')); end
1
julia> opti = ca.Opti();
julia> x = ca.variable(opti);
julia> y = ca.variable(opti);
julia> p = ca.parameter(opti);
julia> ca.minimize(opti, (x - p)^2 + (y - x)^2)
julia> ca.subject_to(opti, x >= 0)
julia> ca.solver(opti, "ipopt", Dict("print_time" => false),
                  Dict("print_level" => 0, "sb" => "yes"))
julia> F = ca.to_function(opti, "F", [p, x], [[x; y], ca.lam_g(opti)],
                          ["p", "x0"], ["xy", "lam"])
Function(F:(p,x0)->(xy[2],lam) MXFunction)
julia> r = F(p=2, x0=1);
julia> r["xy"], r["lam"]
([2, 2], 0.0000)
julia> ca.stats(F)["success"]
true
julia> F = ca.to_function(opti, "F", Dict("p" => p, "x" => x), ["p"], ["x"]);
julia> F(3)
DM(3)
julia> try
           ca.to_function(opti, "F", [p + 1], [x])
       catch e
           println(last(split(sprint(showerror, e), "\n")))
       end
Argument 0 is not purely symbolic.
Extra doc: https://github.com/casadi/casadi/wiki/L_1j
Definition at line 435 of file optistack.cpp.
Referenced by to_function(), and casadi::OptiNode::to_function().
| Function casadi::Opti::to_function | ( | const std::string & | name, |
| const std::vector< MX > & | args, | ||
| const std::vector< MX > & | res, | ||
| const std::vector< std::string > & | name_in, | ||
| const std::vector< std::string > & | name_out, | ||
| const Dict & | opts = Dict() |
||
| ) |
Packs bounds evaluation, the solver call and the evaluation of res into one Function, which is much cheaper to call repeatedly than set_value/solve/value. Inputs corresponding to parameters supply their values; inputs corresponding to variables or dual variables supply the initial guess; anything not listed keeps the value stored in the Opti at the time of the call. Outputs are evaluated at the solution.
A solver failure does not raise by default: the last iterate is returned and the Function's stats() report success False. Pass "error_on_fail": True in the plugin_options of solver() to raise instead. Function options in opts are applied to the result; the entry "helper_options" is applied to the internal evaluation function.
| name | Name of the resulting Function |
| args | List of parameters, decision variables and dual variables (or vertcat of them); each must be purely symbolic and independent, else an error is raised |
| res | List of expressions evaluated at the solution |
| name_in | Optional input names (same length as args) |
| name_out | Optional output names (same length as res) |
| opts | Function options |
>>> opti = Opti()
>>> x = opti.variable()
>>> y = opti.variable()
>>> p = opti.parameter()
>>> opti.minimize((x-p)**2 + (y-x)**2)
>>> opti.subject_to(x >= 0)
>>> opti.solver("ipopt", {"print_time": False}, {"print_level": 0, "sb": "yes"})
>>> F = opti.to_function("F", [p, x], [vertcat(x, y), opti.lam_g],
...                      ["p", "x0"], ["xy", "lam"])
>>> F
Function(F:(p,x0)->(xy[2],lam) MXFunction)
>>> r = F(p=2, x0=1)
>>> r["xy"], r["lam"]
(DM([2, 2]), DM(0.0000))
>>> F.stats()["success"]
True
>>> F = opti.to_function("F", {"p": p, "x": x}, ["p"], ["x"])
>>> F(3)
DM(3)
>>> try:
...   opti.to_function("F", [p+1], [x])
... except Exception as e:
...   print(str(e).splitlines()[-1])
Argument 0 is not purely symbolic.
>> opti = Opti(); x = opti.variable(); y = opti.variable(); p = opti.parameter();
>> opti.minimize((x-p)^2 + (y-x)^2); opti.subject_to(x >= 0);
>> opti.solver('ipopt', struct('print_time', false), struct('print_level', 0, 'sb', 'yes'));
>> F = opti.to_function('F', {p, x}, {vertcat(x, y), opti.lam_g}, {'p', 'x0'}, {'xy', 'lam'});
>> F
F:(p,x0)->(xy[2],lam) MXFunction
>> r = F('p', 2, 'x0', 1); disp(r.xy), disp(r.lam)
[2, 2]
0.0000
>> s = F.stats(); disp(s.success)
1
>> F = opti.to_function('F', struct('p', p, 'x', x), {'p'}, {'x'}); disp(F(3))
3
>> try, opti.to_function('F', {p+1}, {x}); catch e, disp(contains(e.message, 'symbolic')); end
1
julia> opti = ca.Opti();
julia> x = ca.variable(opti);
julia> y = ca.variable(opti);
julia> p = ca.parameter(opti);
julia> ca.minimize(opti, (x - p)^2 + (y - x)^2)
julia> ca.subject_to(opti, x >= 0)
julia> ca.solver(opti, "ipopt", Dict("print_time" => false),
                  Dict("print_level" => 0, "sb" => "yes"))
julia> F = ca.to_function(opti, "F", [p, x], [[x; y], ca.lam_g(opti)],
                          ["p", "x0"], ["xy", "lam"])
Function(F:(p,x0)->(xy[2],lam) MXFunction)
julia> r = F(p=2, x0=1);
julia> r["xy"], r["lam"]
([2, 2], 0.0000)
julia> ca.stats(F)["success"]
true
julia> F = ca.to_function(opti, "F", Dict("p" => p, "x" => x), ["p"], ["x"]);
julia> F(3)
DM(3)
julia> try
           ca.to_function(opti, "F", [p + 1], [x])
       catch e
           println(last(split(sprint(showerror, e), "\n")))
       end
Argument 0 is not purely symbolic.
Extra doc: https://github.com/casadi/casadi/wiki/L_1j
Definition at line 423 of file optistack.cpp.
|
inline |
Definition at line 2600 of file optistack.hpp.
| MX casadi::Opti::ubg | ( | ) | const |
Definition at line 374 of file optistack.cpp.
Merges meta into the dict attached to a variable, parameter, dual variable (or every symbol of an expression) or to a constraint expression passed to subject_to(). Opti itself stores a "stacktrace" entry there in Python and MATLAB, which is what describe()/x_describe() print as "called from".
| m | Symbol, expression of symbols, or constraint expression |
| meta | Dict entries to add (existing keys are overwritten) |
>>> opti = Opti()
>>> x = opti.variable()
>>> opti.update_user_dict(x, {"name": "speed", "unit": "m/s"})
>>> d = opti.user_dict(x)
>>> d["name"], d["unit"], "stacktrace" in d
('speed', 'm/s', True)
>>> con = x >= 0
>>> opti.subject_to(con)
>>> opti.update_user_dict(con, {"name": "nonneg"})
>>> opti.user_dict(con)["name"]
'nonneg'
>> opti = Opti(); x = opti.variable();
>> opti.update_user_dict(x, struct('name', 'speed', 'unit', 'm/s'));
>> d = opti.user_dict(x); fprintf('%s %s %d\n', d.name, d.unit, isfield(d, 'stacktrace'))
speed m/s 1
>> con = x >= 0; opti.subject_to(con); opti.update_user_dict(con, struct('name', 'nonneg'));
>> d = opti.user_dict(con); disp(d.name)
nonneg
julia> opti = ca.Opti();
julia> x = ca.variable(opti);
julia> ca.update_user_dict(opti, x, Dict("name" => "speed", "unit" => "m/s"))
julia> d = ca.user_dict(opti, x);
julia> d["name"], d["unit"], haskey(d, "stacktrace")
("speed", "m/s", true)
julia> con = x >= 0;
julia> ca.subject_to(opti, con)
julia> ca.update_user_dict(opti, con, Dict("name" => "nonneg"))
julia> ca.user_dict(opti, con)["name"]
"nonneg"
Extra doc: https://github.com/casadi/casadi/wiki/L_1o
Definition at line 483 of file optistack.cpp.
Referenced by update_user_dict().
Definition at line 491 of file optistack.cpp.
References update_user_dict().
| m | A single symbol or a constraint expression; other expressions raise an error |
>>> opti = Opti()
>>> x = opti.variable()
>>> sorted(opti.user_dict(x).keys())
['stacktrace']
>>> try:
...   opti.user_dict(x+1)
... except Exception as e:
...   print(str(e).splitlines()[-1])
Symbol expected, got expression.
>> opti = Opti(); x = opti.variable(); disp(fieldnames(opti.user_dict(x)))
{'stacktrace'}
>> try, opti.user_dict(x+1); catch e, disp(contains(e.message, 'Symbol expected')); end
1
julia> opti = ca.Opti();
julia> x = ca.variable(opti);
julia> sort(collect(keys(ca.user_dict(opti, x))))
1-element Vector{String}:
 "stacktrace"
julia> try
           ca.user_dict(opti, x + 1)
       catch e
           println(last(split(sprint(showerror, e), "\n")))
       end
Symbol expected, got expression.
Extra doc: https://github.com/casadi/casadi/wiki/L_2mw
Definition at line 496 of file optistack.cpp.
Variables take the latest solver result, parameters their set_value(), dual variables the latest multipliers. Before the first solve(), or after set_initial()/set_value() changed the state, an expression involving variables raises an error unless every variable in it is overruled through values; parameter-only expressions always work. After a failed solve() the latest iterate is returned (the same holds for opti.debug.value()). A variable that does not appear in the problem raises an error.
| x | Expression in the symbols of this instance (an MX). A DM is returned as is. SX expressions are not supported: a NaN matrix of the same sparsity is returned. |
| values | Optional list of assignments var==value (e.g. opti.initial()) that overrule the stored values for this evaluation only |
>>> opti = Opti()
>>> x = opti.variable()
>>> p = opti.parameter()
>>> opti.minimize((x-p)**2)
>>> opti.set_value(p, 3)
>>> opti.value(2*p)
6.0
>>> try:
...   opti.value(x)
... except Exception as e:
...   print(str(e).splitlines()[-1])
This action is forbidden since you have not solved the Opti stack yet (with calling 'solve').
>>> opti.value(x+p, [x==1]), opti.value(x**2, opti.initial())
(4.0, 0.0)
>>> opti.solver("ipopt", {"print_time": False}, {"print_level": 0, "sb": "yes"})
>>> sol = opti.solve()
>>> opti.value(x), sol.value(x), sol.value(x+p, [p==10])
(3.0, 3.0, 13.0)
>>> type(sol.value(vertcat(x, p))).__name__, sol.value(DM([1, 2]))
('ndarray', array([1., 2.]))
>> opti = Opti(); x = opti.variable(); p = opti.parameter();
>> opti.minimize((x-p)^2); opti.set_value(p, 3);
>> opti.value(2*p)
6
>> try, opti.value(x); catch e, disp(contains(e.message, 'not solved the Opti stack')); end
1
>> opti.value(x+p, {x==1}), opti.value(x^2, opti.initial())
4
0
>> opti.solver('ipopt', struct('print_time', false), struct('print_level', 0, 'sb', 'yes'));
>> sol = opti.solve();
>> opti.value(x), sol.value(x), sol.value(x+p, {p==10})
3
3
13
>> v = sol.value(vertcat(x, p)); disp(class(v)), disp(size(v)), disp(sol.value(DM([1; 2]))')
double
2 1
1 2
julia> opti = ca.Opti();
julia> x = ca.variable(opti);
julia> p = ca.parameter(opti);
julia> ca.minimize(opti, (x - p)^2)
julia> ca.set_value(opti, p, 3)
julia> ca.value(opti, 2*p)
6.0
julia> try
           ca.value(opti, x)
       catch e
           println(last(split(sprint(showerror, e), "\n")))
       end
This action is forbidden since you have not solved the Opti stack yet (with calling 'solve').
julia> opti.value(x + p, [x == 1]), opti.value(x^2, ca.initial(opti))
(4.0, 0.0)
julia> ca.solver(opti, "ipopt", Dict("print_time" => false),
                  Dict("print_level" => 0, "sb" => "yes"))
julia> sol = ca.solve(opti);
julia> ca.value(opti, x), ca.value(sol, x)
(3.0, 3.0)
julia> sol.value(x + p, [p == 10])
13.0
julia> ca.value(sol, [x; p]), ca.value(sol, ca.DM([1, 2]))
([3.0, 3.0], [1.0, 2.0])
Extra doc: https://github.com/casadi/casadi/wiki/L_2mv
Definition at line 238 of file optistack.cpp.
References x().
Variables take the latest solver result, parameters their set_value(), dual variables the latest multipliers. Before the first solve(), or after set_initial()/set_value() changed the state, an expression involving variables raises an error unless every variable in it is overruled through values; parameter-only expressions always work. After a failed solve() the latest iterate is returned (the same holds for opti.debug.value()). A variable that does not appear in the problem raises an error.
| x | Expression in the symbols of this instance (an MX). A DM is returned as is. SX expressions are not supported: a NaN matrix of the same sparsity is returned. |
| values | Optional list of assignments var==value (e.g. opti.initial()) that overrule the stored values for this evaluation only |
>>> opti = Opti()
>>> x = opti.variable()
>>> p = opti.parameter()
>>> opti.minimize((x-p)**2)
>>> opti.set_value(p, 3)
>>> opti.value(2*p)
6.0
>>> try:
...   opti.value(x)
... except Exception as e:
...   print(str(e).splitlines()[-1])
This action is forbidden since you have not solved the Opti stack yet (with calling 'solve').
>>> opti.value(x+p, [x==1]), opti.value(x**2, opti.initial())
(4.0, 0.0)
>>> opti.solver("ipopt", {"print_time": False}, {"print_level": 0, "sb": "yes"})
>>> sol = opti.solve()
>>> opti.value(x), sol.value(x), sol.value(x+p, [p==10])
(3.0, 3.0, 13.0)
>>> type(sol.value(vertcat(x, p))).__name__, sol.value(DM([1, 2]))
('ndarray', array([1., 2.]))
>> opti = Opti(); x = opti.variable(); p = opti.parameter();
>> opti.minimize((x-p)^2); opti.set_value(p, 3);
>> opti.value(2*p)
6
>> try, opti.value(x); catch e, disp(contains(e.message, 'not solved the Opti stack')); end
1
>> opti.value(x+p, {x==1}), opti.value(x^2, opti.initial())
4
0
>> opti.solver('ipopt', struct('print_time', false), struct('print_level', 0, 'sb', 'yes'));
>> sol = opti.solve();
>> opti.value(x), sol.value(x), sol.value(x+p, {p==10})
3
3
13
>> v = sol.value(vertcat(x, p)); disp(class(v)), disp(size(v)), disp(sol.value(DM([1; 2]))')
double
2 1
1 2
julia> opti = ca.Opti();
julia> x = ca.variable(opti);
julia> p = ca.parameter(opti);
julia> ca.minimize(opti, (x - p)^2)
julia> ca.set_value(opti, p, 3)
julia> ca.value(opti, 2*p)
6.0
julia> try
           ca.value(opti, x)
       catch e
           println(last(split(sprint(showerror, e), "\n")))
       end
This action is forbidden since you have not solved the Opti stack yet (with calling 'solve').
julia> opti.value(x + p, [x == 1]), opti.value(x^2, ca.initial(opti))
(4.0, 0.0)
julia> ca.solver(opti, "ipopt", Dict("print_time" => false),
                  Dict("print_level" => 0, "sb" => "yes"))
julia> sol = ca.solve(opti);
julia> ca.value(opti, x), ca.value(sol, x)
(3.0, 3.0)
julia> sol.value(x + p, [p == 10])
13.0
julia> ca.value(sol, [x; p]), ca.value(sol, ca.DM([1, 2]))
([3.0, 3.0], [1.0, 2.0])
Extra doc: https://github.com/casadi/casadi/wiki/L_2mv
Definition at line 229 of file optistack.cpp.
References x().
Referenced by casadi::OptiSol::value().
Variables take the latest solver result, parameters their set_value(), dual variables the latest multipliers. Before the first solve(), or after set_initial()/set_value() changed the state, an expression involving variables raises an error unless every variable in it is overruled through values; parameter-only expressions always work. After a failed solve() the latest iterate is returned (the same holds for opti.debug.value()). A variable that does not appear in the problem raises an error.
| x | Expression in the symbols of this instance (an MX). A DM is returned as is. SX expressions are not supported: a NaN matrix of the same sparsity is returned. |
| values | Optional list of assignments var==value (e.g. opti.initial()) that overrule the stored values for this evaluation only |
>>> opti = Opti()
>>> x = opti.variable()
>>> p = opti.parameter()
>>> opti.minimize((x-p)**2)
>>> opti.set_value(p, 3)
>>> opti.value(2*p)
6.0
>>> try:
...   opti.value(x)
... except Exception as e:
...   print(str(e).splitlines()[-1])
This action is forbidden since you have not solved the Opti stack yet (with calling 'solve').
>>> opti.value(x+p, [x==1]), opti.value(x**2, opti.initial())
(4.0, 0.0)
>>> opti.solver("ipopt", {"print_time": False}, {"print_level": 0, "sb": "yes"})
>>> sol = opti.solve()
>>> opti.value(x), sol.value(x), sol.value(x+p, [p==10])
(3.0, 3.0, 13.0)
>>> type(sol.value(vertcat(x, p))).__name__, sol.value(DM([1, 2]))
('ndarray', array([1., 2.]))
>> opti = Opti(); x = opti.variable(); p = opti.parameter();
>> opti.minimize((x-p)^2); opti.set_value(p, 3);
>> opti.value(2*p)
6
>> try, opti.value(x); catch e, disp(contains(e.message, 'not solved the Opti stack')); end
1
>> opti.value(x+p, {x==1}), opti.value(x^2, opti.initial())
4
0
>> opti.solver('ipopt', struct('print_time', false), struct('print_level', 0, 'sb', 'yes'));
>> sol = opti.solve();
>> opti.value(x), sol.value(x), sol.value(x+p, {p==10})
3
3
13
>> v = sol.value(vertcat(x, p)); disp(class(v)), disp(size(v)), disp(sol.value(DM([1; 2]))')
double
2 1
1 2
julia> opti = ca.Opti();
julia> x = ca.variable(opti);
julia> p = ca.parameter(opti);
julia> ca.minimize(opti, (x - p)^2)
julia> ca.set_value(opti, p, 3)
julia> ca.value(opti, 2*p)
6.0
julia> try
           ca.value(opti, x)
       catch e
           println(last(split(sprint(showerror, e), "\n")))
       end
This action is forbidden since you have not solved the Opti stack yet (with calling 'solve').
julia> opti.value(x + p, [x == 1]), opti.value(x^2, ca.initial(opti))
(4.0, 0.0)
julia> ca.solver(opti, "ipopt", Dict("print_time" => false),
                  Dict("print_level" => 0, "sb" => "yes"))
julia> sol = ca.solve(opti);
julia> ca.value(opti, x), ca.value(sol, x)
(3.0, 3.0)
julia> sol.value(x + p, [p == 10])
13.0
julia> ca.value(sol, [x; p]), ca.value(sol, ca.DM([1, 2]))
([3.0, 3.0], [1.0, 2.0])
Extra doc: https://github.com/casadi/casadi/wiki/L_2mv
Definition at line 246 of file optistack.cpp.
References x().
| std::vector< MX > casadi::Opti::value_parameters | ( | ) | const |
| std::vector< MX > casadi::Opti::value_variables | ( | ) | const |
value_variables() gives value==var for every variable with its latest solver result; value_parameters() gives value==par for every parameter with its set value. Both feed set_initial()/set_value() to transfer a solution to the next solve or to another Opti.
>>> opti = Opti()
>>> x = opti.variable()
>>> p = opti.parameter()
>>> opti.minimize((x-p)**2)
>>> opti.set_value(p, 2)
>>> opti.solver("ipopt", {"print_time": False}, {"print_level": 0, "sb": "yes"})
>>> sol = opti.solve()
>>> print(opti.value_variables(), opti.value_parameters())
[MX((2==opti..._x_1))] [MX((2==opti..._p_1))]
>>> opti.set_initial(sol.value_variables())
>>> opti.value(x, opti.initial())
2.0
>> opti = Opti(); x = opti.variable(); p = opti.parameter();
>> opti.minimize((x-p)^2); opti.set_value(p, 2);
>> opti.solver('ipopt', struct('print_time', false), struct('print_level', 0, 'sb', 'yes'));
>> sol = opti.solve();
>> vv = opti.value_variables(); vp = opti.value_parameters(); disp(vv{1}), disp(vp{1})
(2==opti..._x_1)
(2==opti..._p_1)
>> opti.set_initial(sol.value_variables()); disp(opti.value(x, opti.initial()))
2
julia> opti = ca.Opti();
julia> x = ca.variable(opti);
julia> p = ca.parameter(opti);
julia> ca.minimize(opti, (x - p)^2)
julia> ca.set_value(opti, p, 2)
julia> ca.solver(opti, "ipopt", Dict("print_time" => false),
                  Dict("print_level" => 0, "sb" => "yes"))
julia> sol = ca.solve(opti);
julia> print(ca.value_variables(opti), " ", ca.value_parameters(opti))
MX[(2==opti..._x_1)] MX[(2==opti..._p_1)]
julia> opti.set_initial(ca.value_variables(sol))
julia> opti.value(x, ca.initial(opti))
2.0
Extra doc: https://github.com/casadi/casadi/wiki/L_267
Definition at line 286 of file optistack.cpp.
Referenced by casadi::OptiSol::value_variables().
| MX casadi::Opti::variable | ( | casadi_int | n = 1, |
| casadi_int | m = 1, |
||
| const std::string & | attribute = "full" |
||
| ) |
Returns an MX symbol of the requested shape, registered with this Opti instance. Variables are stacked into the solver's x vector in order of creation, so the order of variable() calls determines the layout of x and of lam_x. A variable that does not appear in the objective or the constraints is simply left out of the problem, but asking for its value after solve() raises an error.
With attribute "symmetric" (square shapes only) the returned expression is a symmetric matrix built from n*(n+1)/2 underlying scalars.
The default initial guess is 0; change it with set_initial().
| n | Number of rows (default 1) |
| m | Number of columns (default 1) |
| attribute | "full" (default) or "symmetric"; anything else raises an error |
>>> opti = Opti()
>>> x = opti.variable()
>>> X = opti.variable(3, 2)
>>> x.shape, X.shape, X.is_symbolic()
((1, 1), (3, 2), True)
>>> S = opti.variable(2, 2, "symmetric")
>>> S.shape, S.is_symbolic()
((2, 2), False)
>>> opti.minimize(sumsqr(X) + x**2 + sumsqr(S))
>>> opti.nx
10
>>> try:
...   opti.variable(2, 3, "symmetric")
... except Exception as e:
...   print(str(e).splitlines()[-1])
You specified attribute 'symmetric', while matrix is not even square, but 2-by-3.
>> opti = Opti(); x = opti.variable(); X = opti.variable(3, 2);
>> size(x), size(X), X.is_symbolic()
1 1
3 2
1
>> S = opti.variable(2, 2, 'symmetric'); disp(size(S)), disp(S.is_symbolic())
2 2
0
>> opti.minimize(sumsqr(X) + x^2 + sumsqr(S)); disp(opti.nx)
10
>> try, opti.variable(2, 3, 'symmetric'); catch e, disp(contains(e.message, 'not even')); end
1
julia> opti = ca.Opti();
julia> x = ca.variable(opti);
julia> X = ca.variable(opti, 3, 2);
julia> size(x), size(X), ca.is_symbolic(X)
((1, 1), (3, 2), true)
julia> S = ca.variable(opti, 2, 2, "symmetric");
julia> size(S), ca.is_symbolic(S)
((2, 2), false)
julia> ca.minimize(opti, ca.sumsqr(X) + x^2 + ca.sumsqr(S))
julia> ca.nx(opti)
10
julia> try
           ca.variable(opti, 2, 3, "symmetric")
       catch e
           println(last(split(sprint(showerror, e), "\n")))
       end
You specified attribute 'symmetric', while matrix is not even square, but 2-by-3.
Extra doc: https://github.com/casadi/casadi/wiki/L_18
Definition at line 51 of file optistack.cpp.
Definition at line 67 of file optistack.cpp.
Definition at line 59 of file optistack.cpp.
|
inherited |
Extra doc: https://github.com/casadi/casadi/wiki/L_aw
Definition at line 130 of file generic_shared_impl.hpp.
| MX casadi::Opti::x | ( | ) | const |
The vector the solver optimizes over, in order of variable() creation, restricted to the variables that appear in the problem. Use it with jacobian(), hessian() or to_function(). In Python this is a read-only property.
>>> opti = Opti()
>>> x = opti.variable(2)
>>> y = opti.variable()
>>> opti.minimize(sumsqr(x) + y**2)
>>> opti.x.shape
(3, 1)
>>> opti.solver("ipopt", {"print_time": False}, {"print_level": 0, "sb": "yes"})
>>> sol = opti.solve()
>>> sol.value(jacobian(opti.f, opti.x))
array([0., 0., 0.])
>> opti = Opti(); x = opti.variable(2); y = opti.variable();
>> opti.minimize(sumsqr(x) + y^2); disp(size(opti.x))
3 1
>> opti.solver('ipopt', struct('print_time', false), struct('print_level', 0, 'sb', 'yes'));
>> sol = opti.solve(); disp(sol.value(jacobian(opti.f, opti.x)))
0 0 0
julia> opti = ca.Opti();
julia> x = ca.variable(opti, 2);
julia> y = ca.variable(opti);
julia> ca.minimize(opti, ca.sumsqr(x) + y^2)
julia> size(ca.x(opti))
(3, 1)
julia> ca.solver(opti, "ipopt", Dict("print_time" => false),
                  Dict("print_level" => 0, "sb" => "yes"))
julia> sol = ca.solve(opti);
julia> ca.value(sol, ca.jacobian(ca.f(opti), ca.x(opti)))
3-element Vector{Float64}:
 0.0
 0.0
 0.0
Extra doc: https://github.com/casadi/casadi/wiki/L_26b
Definition at line 334 of file optistack.cpp.
Referenced by casadi::OptiAdvanced::describe(), set_domain(), set_initial(), set_linear_scale(), set_value(), and value().
| DM casadi::Opti::x_linear_scale | ( | ) | const |
Definition at line 391 of file optistack.cpp.
| DM casadi::Opti::x_linear_scale_offset | ( | ) | const |
Definition at line 399 of file optistack.cpp.
|
friend |
Definition at line 237 of file optistack.hpp.